Sensing hardware for machines that learn.
We source, validate and build the capture and sensing hardware behind robot learning, wearables and edge vision — egocentric rigs, trackers, gloves, grippers, collars and AI boxes — and we measure it before you pay for it.
What exists, what it really does, and where to get it.
60 devices, modules and parts tracked across Shenzhen, Shanghai, Dongguan and beyond from a network of 100+ suppliers. Ask for any of them and we handle samples, testing and supply.
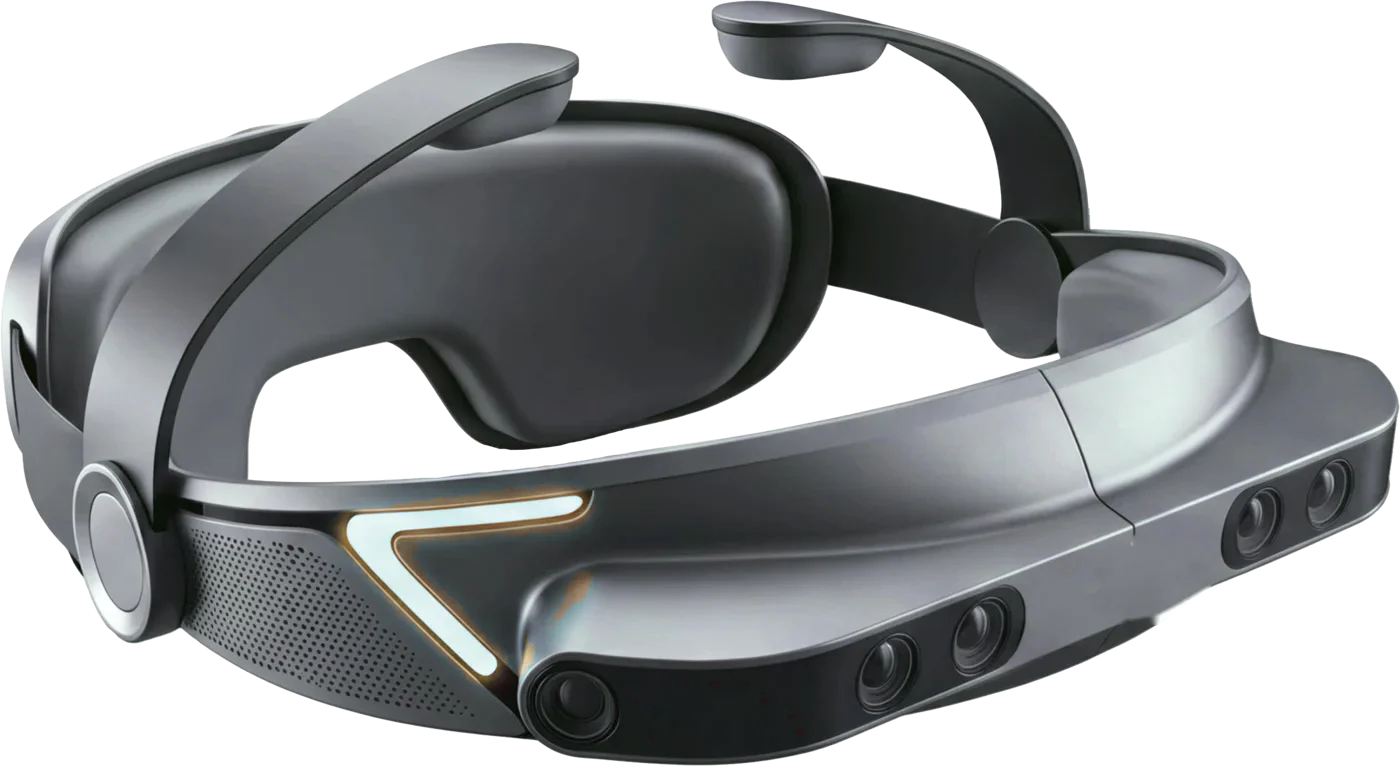
Head-mounted 6-camera data terminal (FPGA sync)
3 binocular pairs: wide RGB ×2, fisheye RGB ×2, wide IR ×2 · FPGA unified trigger; sub-microsecond across RGB / IR / IMU / audio (claim)
Request info →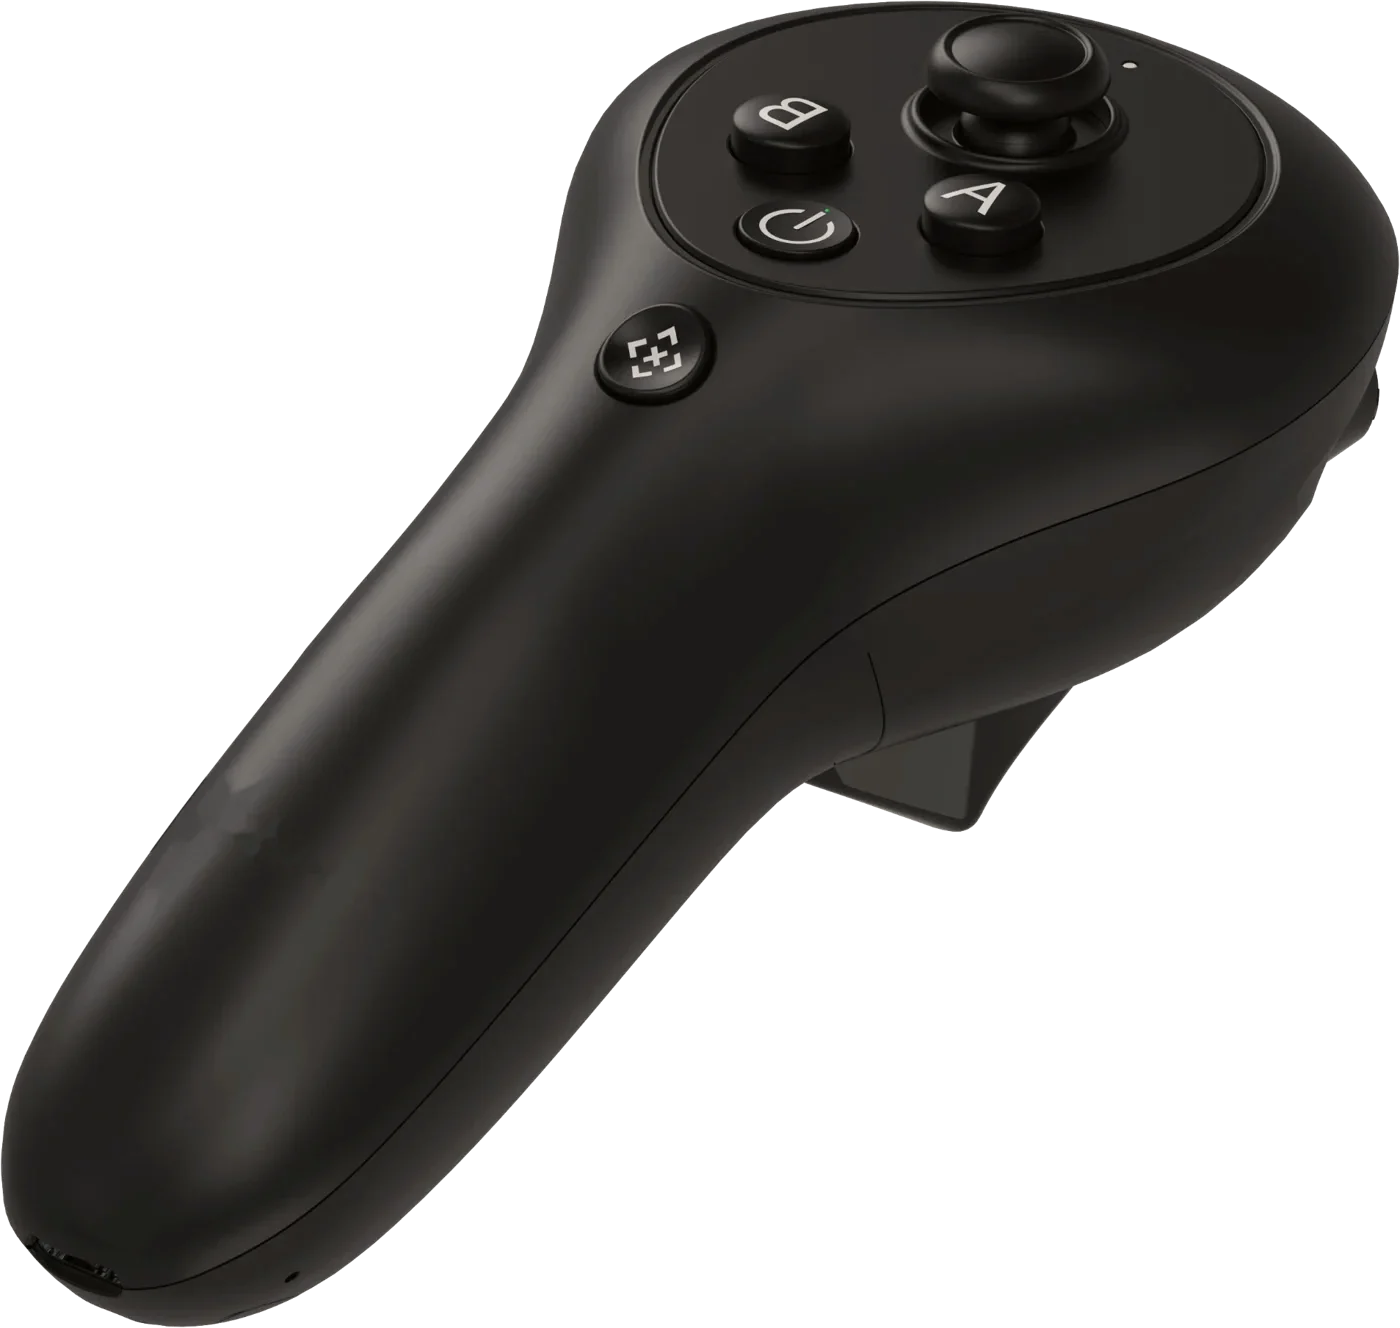
6DoF self-tracking controller
Inside-out visual SLAM, 2 × 640×480 mono global-shutter fisheye, DFOV 160° · 6-axis, 1000 Hz
Request info →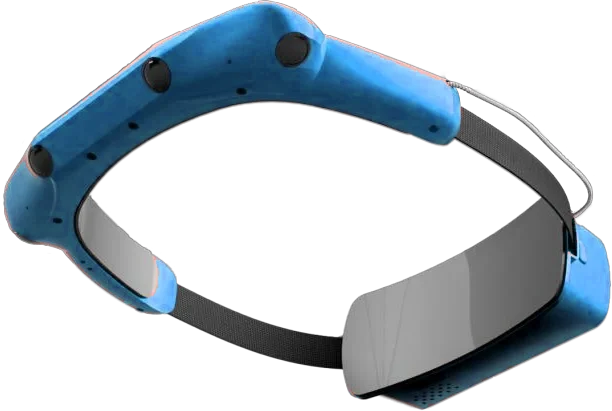
RK3576 four-camera egocentric headset
4 × 2.3 MP global shutter, 1920×1200 @ 30 fps (up to 60) · 206° × 117°
Request info →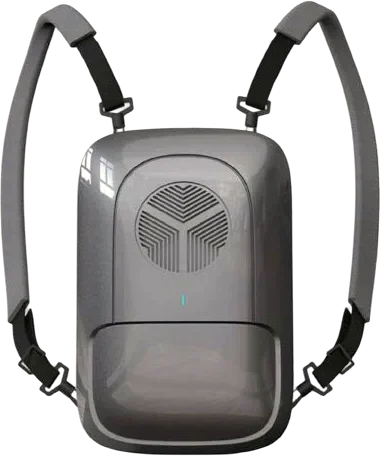
GMSL2 backpack capture system (head band + wrists + EMG)
Front stereo + 2 left + 2 right cameras over GMSL2 · Wrist camera units (GMSL2 + USB-A) and EMG bands (Wi-Fi), left and right
Request info →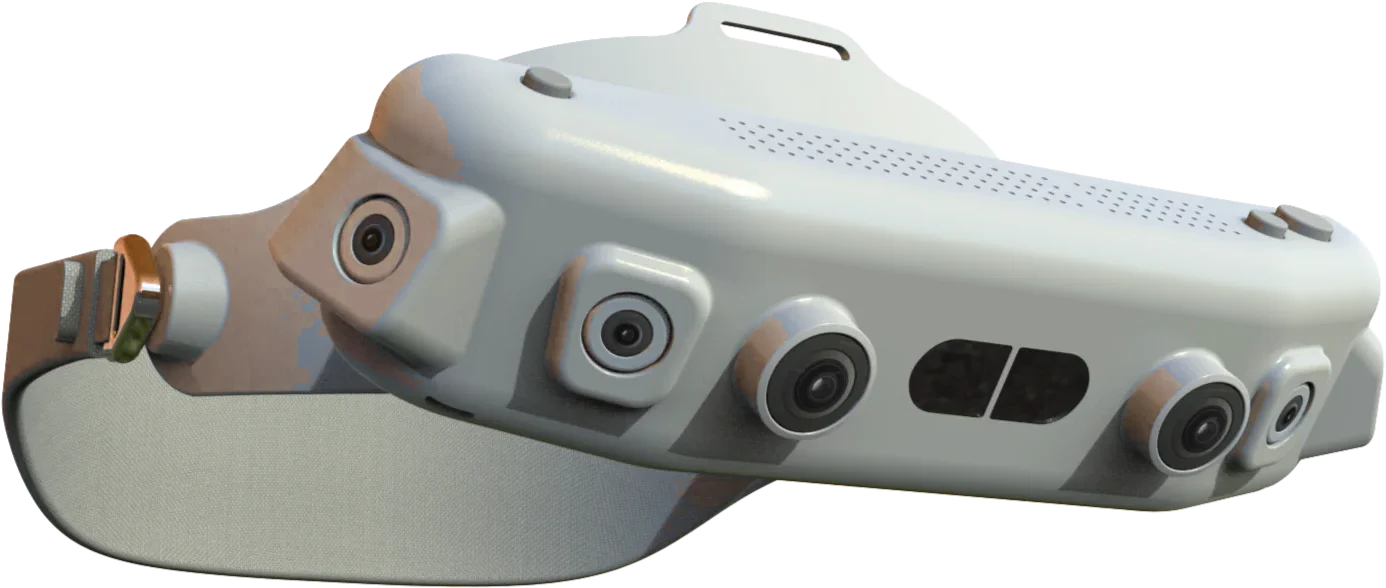
Data-collection HMD: 4 fisheye + 2 RGB + ToF
4 × 640×480 mono global shutter fisheye, 25–50 fps, DFOV ≥ 160°, RAW8, IR pass-through · 2 × 1920×1080 @ 60 fps global shutter, DFOV 179°
Request info →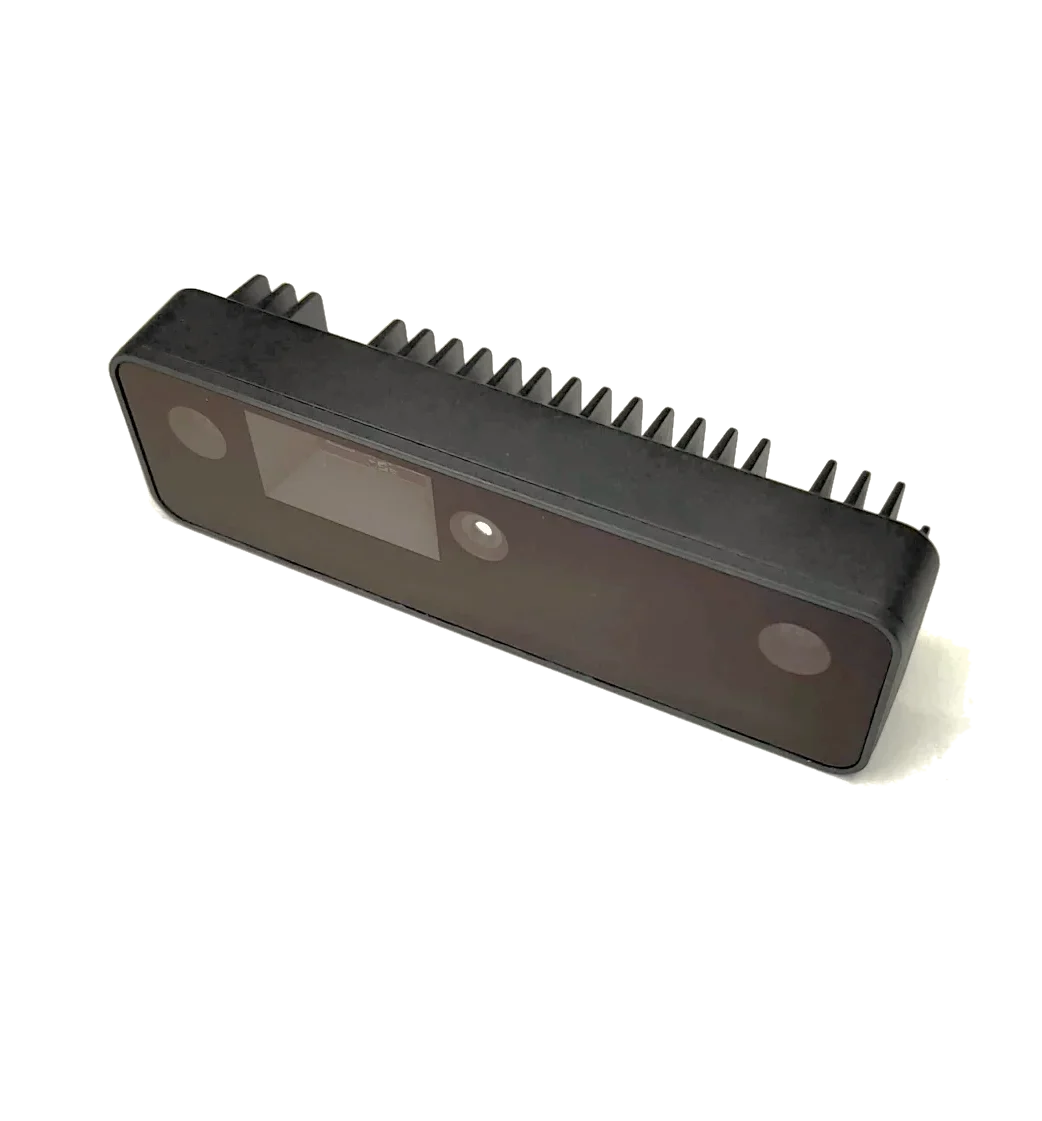
Active-stereo depth + AI camera
2 × OV9282 1 MP global shutter, no IR filter, up to 120 fps · IMX378 12 MP, 4056×3040
Request info →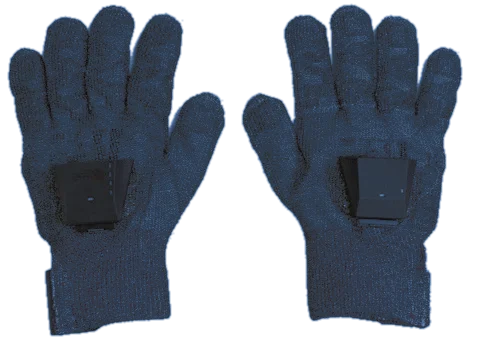
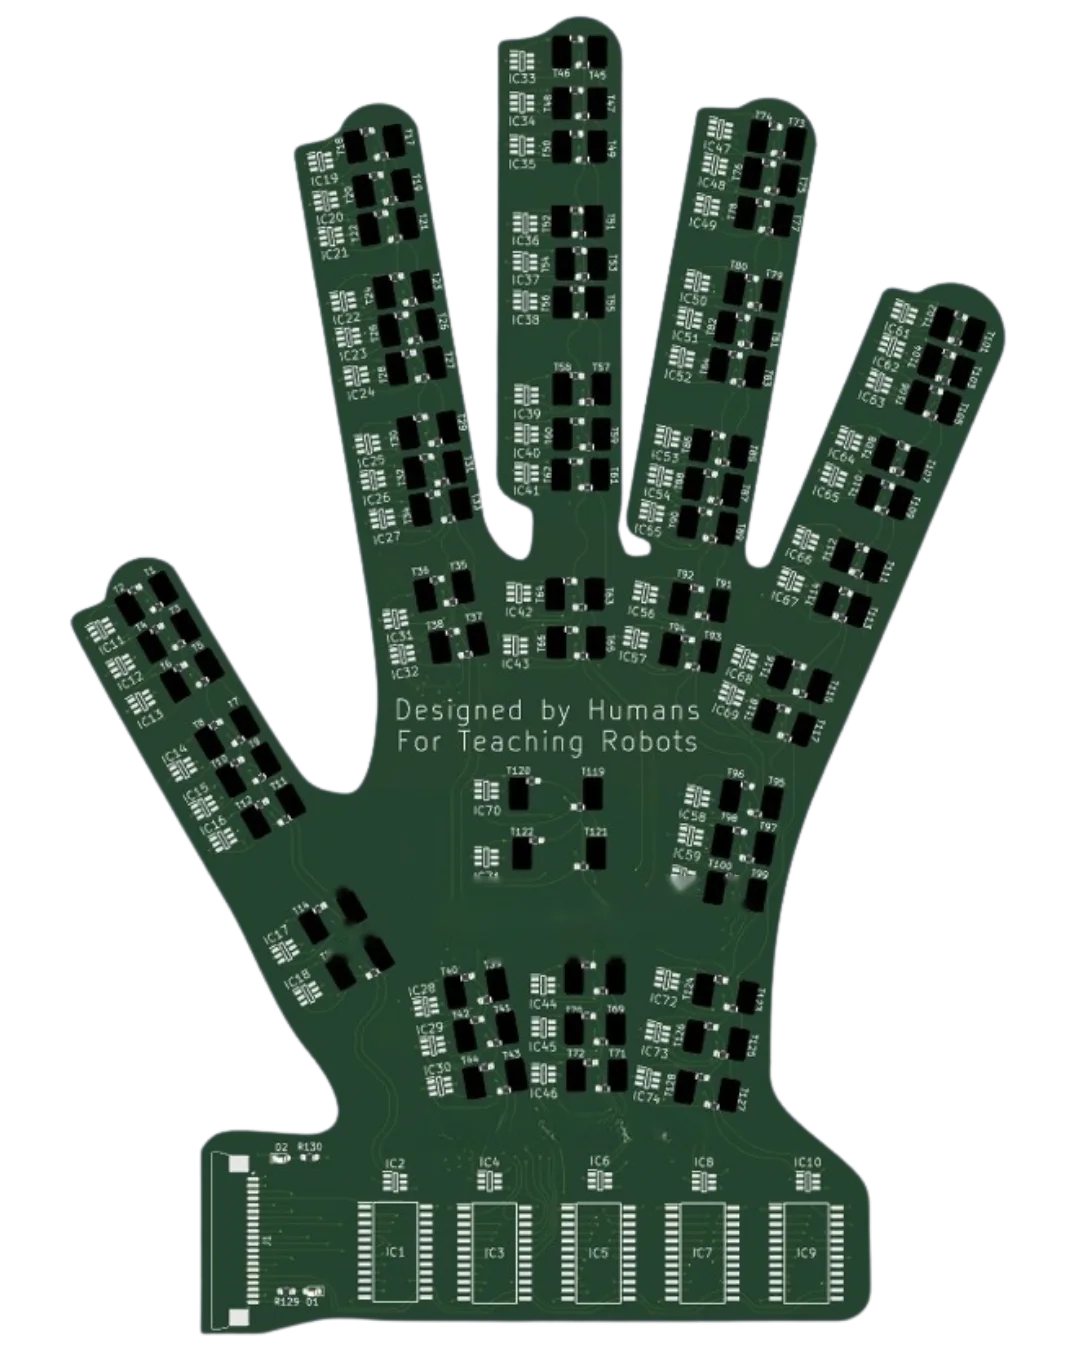
65-element wireless pressure glove
65 tactile elements across palm and fingers · BLE wireless, battery powered
Request info →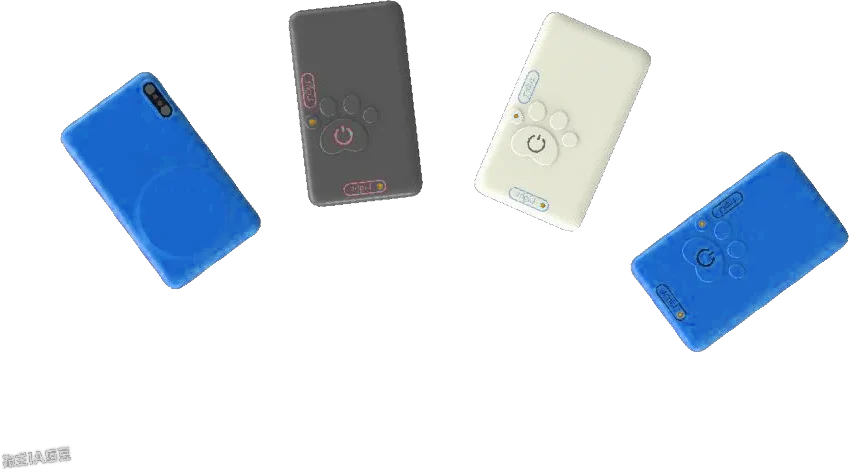
Compact 4G pet GPS tracker
4G LTE Cat.1 · 42 × 42 × 21 mm; 27.5 g; IP67
Request info →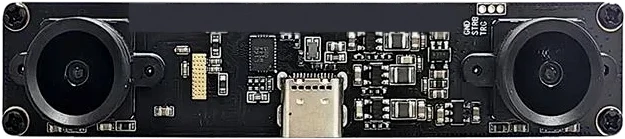
Stereo 1 MP global-shutter USB 3 board, trigger pins
2 × 1/4" global shutter, 1280×800, 3.0 µm · 2560×800 @ 60 fps MJPEG / 30 fps YUV; 1280×800 up to 120 fps
Request info →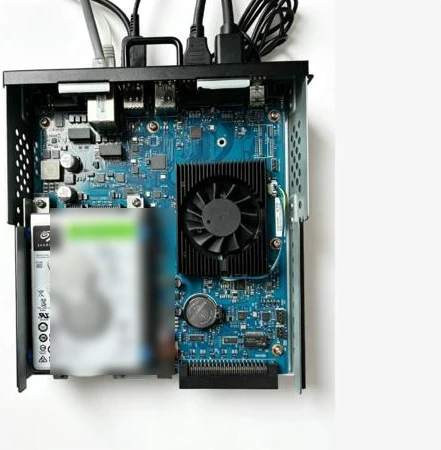
RK3588 compact edge host (3 × GbE, PoE, SATA)
RK3588: 4×A76 + 4×A55, Mali-G610, 6 TOPS NPU · 8 GB RAM, 16 GB eMMC, 2.5" SATA bay
Request info →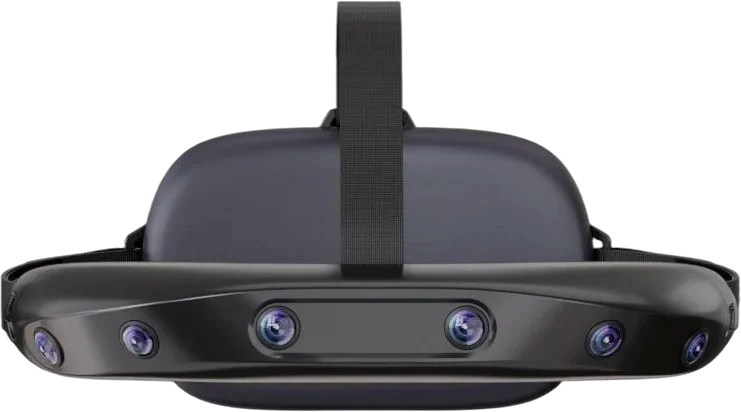
EGO-6 egocentric capture headset (270°, 6 cameras)
6 × colour global shutter, 1600×1300, 30 fps (60 fps option), combined 270° FOV · H160° × V120°, intrinsics stored in EEPROM
Request info →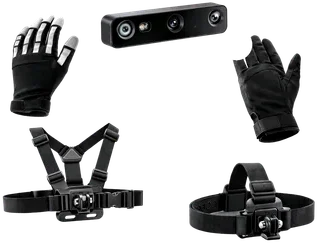
Tactile glove + head/chest vision kit
132 per glove (12 per finger + 72 palm), 5 bend sensors · 0.01 N fingertip; 325 N max
Request info →Factories, labs, kitchens, streets. Real work, first-person.
10,000+ hours of egocentric and manipulation data a month across Malaysia, Indonesia, Vietnam, Thailand and the Philippines — commercial and household sites, phones, egocentric glasses and tactile gloves, with capacity growing every month.
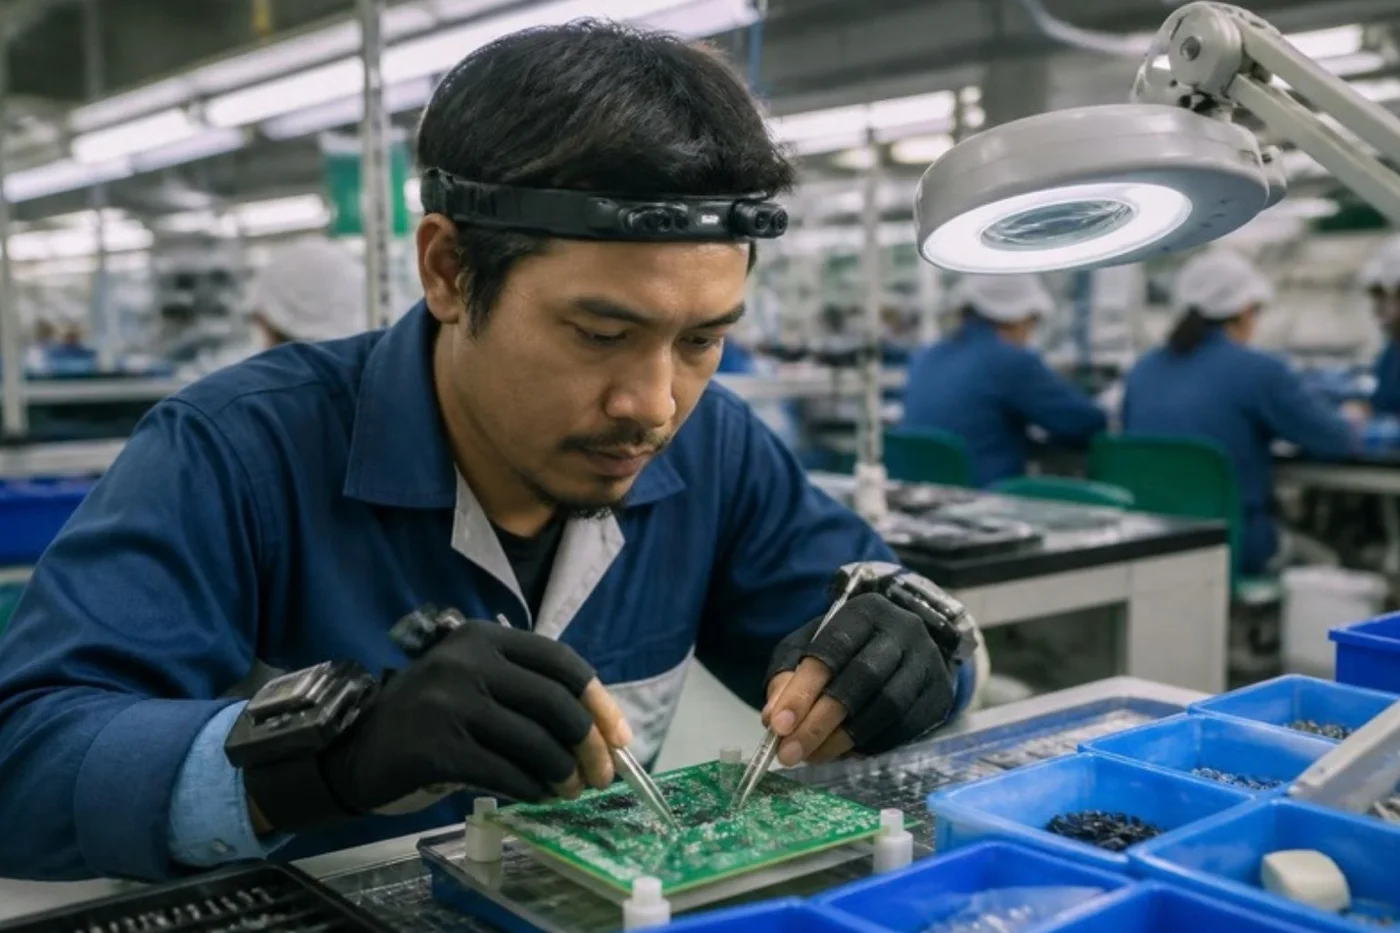
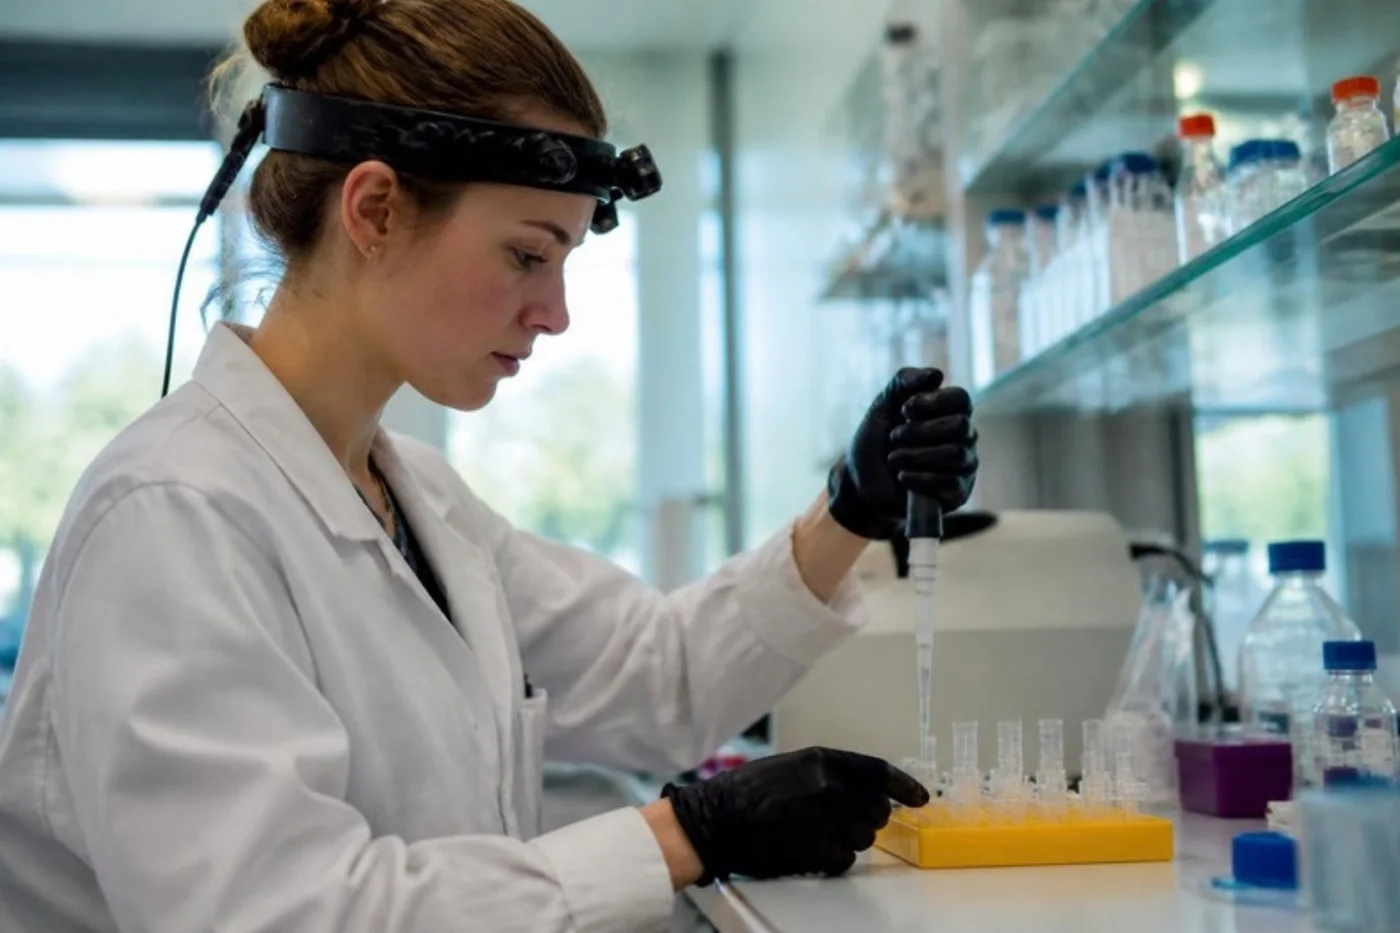
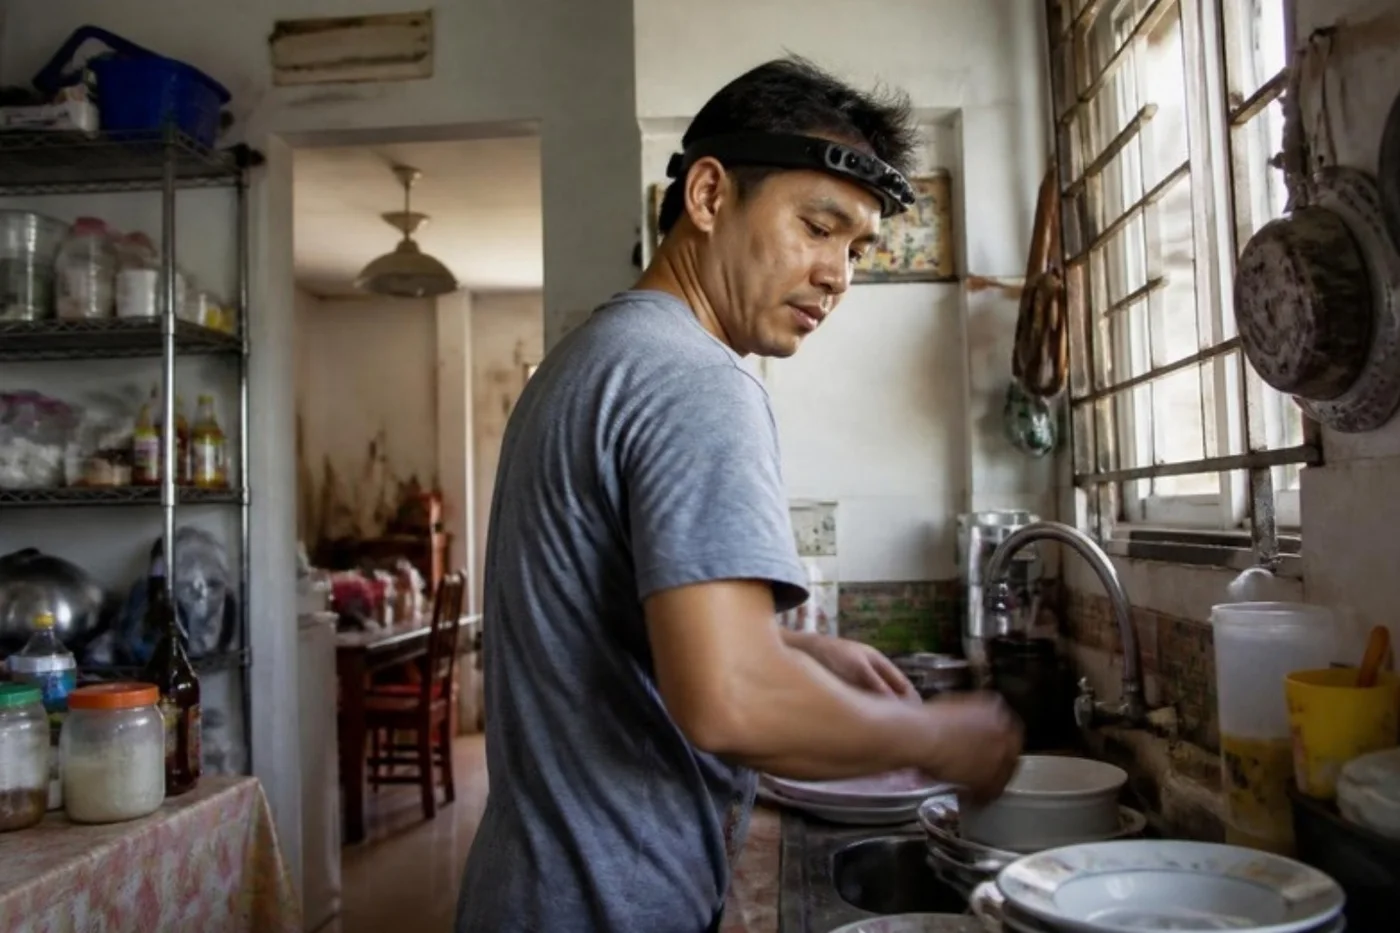
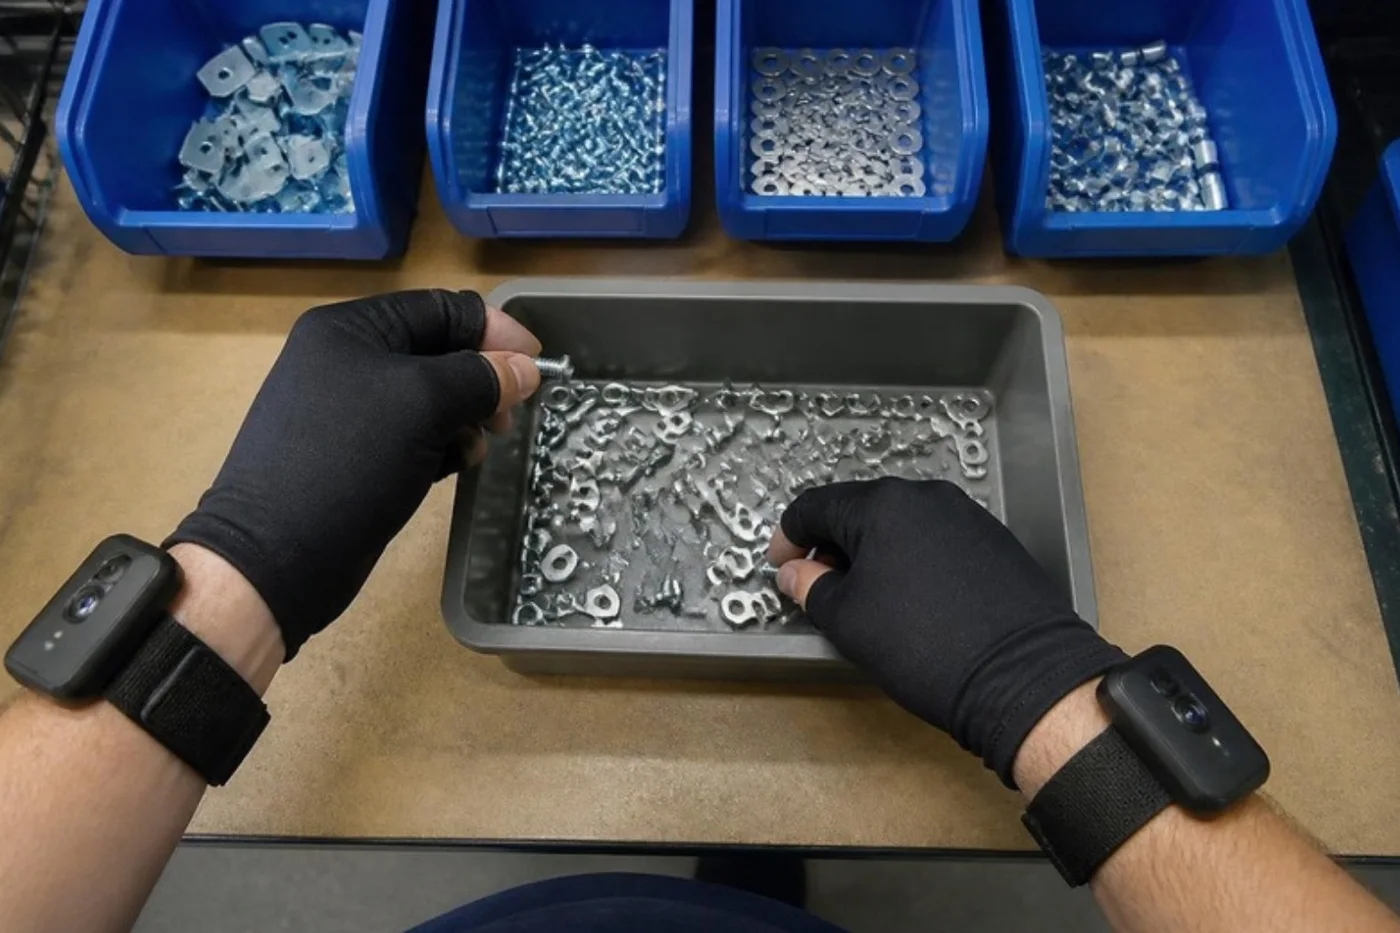
Illustrative scenes. Collection runs with phones, egocentric glasses and headsets, and tactile gloves.
Four practices. One standard: measured, owned, shippable.
Robot-learning data hardware
Egocentric headsets, body and object trackers, UMI grippers and synchronised multi-camera systems for teams training robot foundation models.
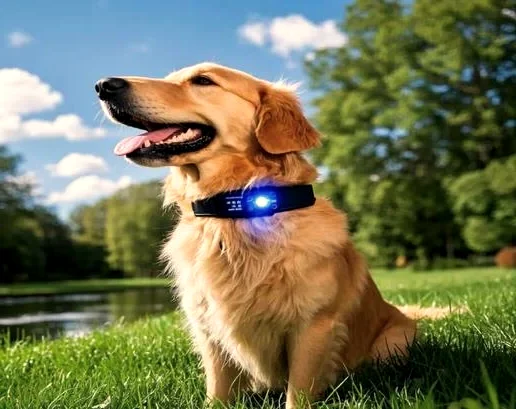
Wearables & health sensing
Connected collars, smart footwear, rings, earbuds and gloves — taken from a proven platform to a product you own, with your data on your cloud.
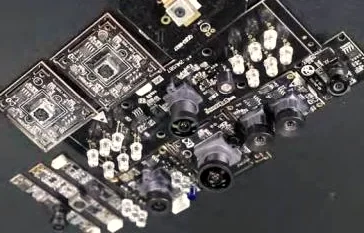
Edge vision & AI boxes
Rockchip, NVIDIA Jetson and Hailo edge boxes, smart cameras and GMSL camera systems for retail analytics and industrial inspection.
Data-collection operations
Egocentric and manipulation data collection for robotics labs — 10,000+ hours a month across five Southeast Asian countries, in commercial and household environments.
We don't just source it. We design it, wire it, break it.
Reports, benchmarks and buyer guides from the field.
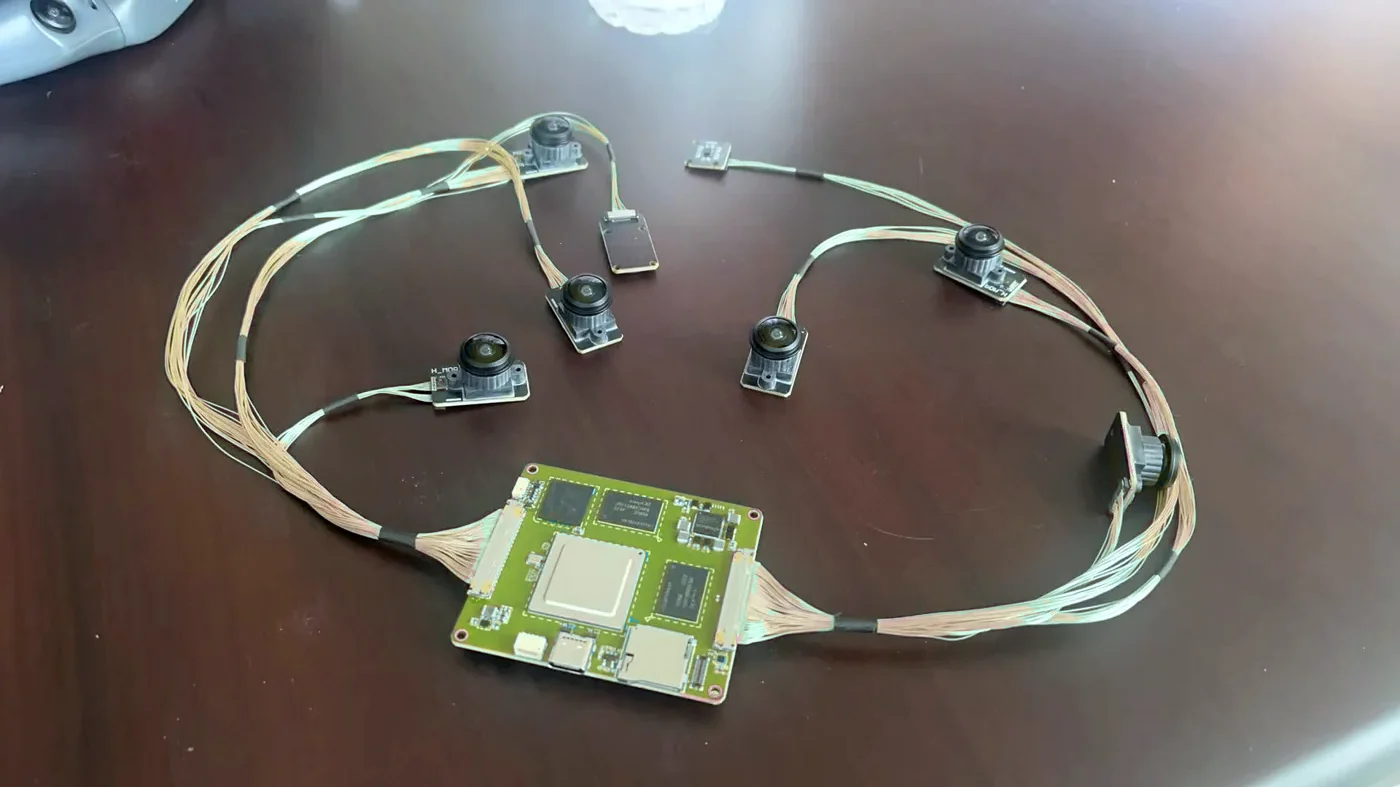
Compute for Capture Devices and Edge Boxes: RK3576, RK3588, Allwinner A733, Raspberry Pi 5 and Jetson Orin
Read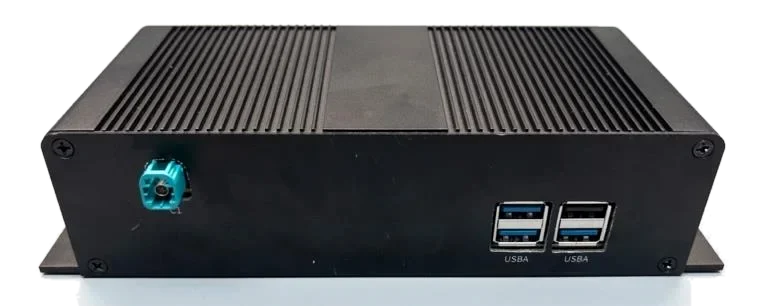
Edge AI Boxes for Retail and Inspection: A Hardware Checklist That Survives the Pilot
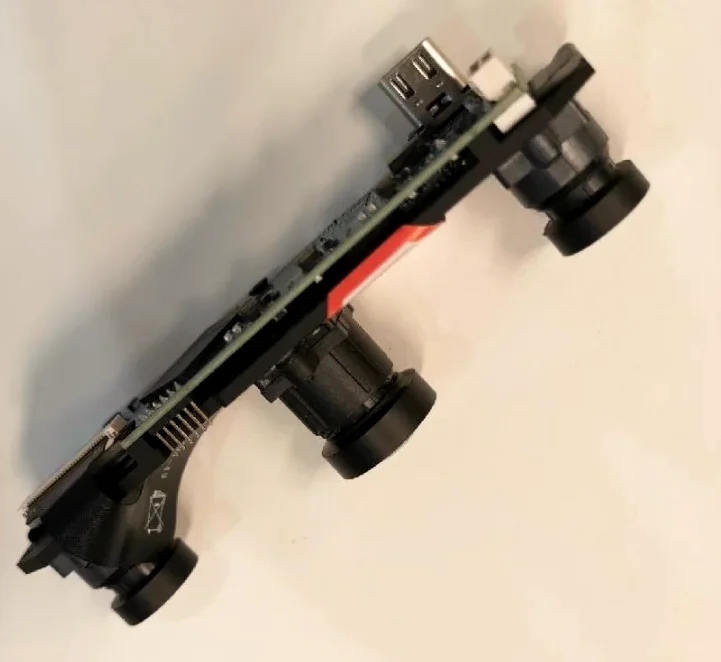
ReadEgocentric Data-Capture Hardware: 2026 Buyer's Benchmark
ReadGlobal-Shutter Sensors for Robot Tracking and Egocentric Capture: OV9281, AR0234, IMX296 and Alternatives
ReadThe Hardware RFP Clauses That Decide Who Owns Your Product: Firmware, Data, Calibration and Design Files
Read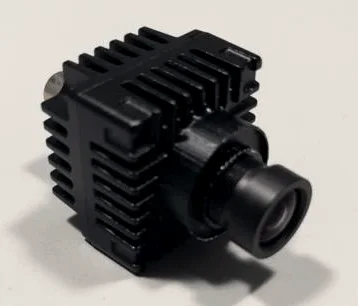
MIPI, GMSL2, USB3 or 10GbE? Choosing the Camera Link for Multi-Camera Robots
ReadProgrammes we run. Clients kept anonymous.
Measure before money.
Specify
Your requirement becomes acceptance criteria a vendor can quote and we can test.
Source
Existing products first, from our index across Shenzhen, Dongguan, Shanghai and Hangzhou.
Validate
Timing, raw-data access, calibration and long-run stability measured on real units.
Build & ship
Gated prototype programmes, then production, QC and logistics with full BOM transparency.
Building hardware that has to learn? Talk to us.
Send a spec, a sketch, or just the problem. We reply within 24 hours (HKT), usually the same day.