← Hardware Index
Egocentric headset
Data-collection HMD: 4 fisheye + 2 RGB + ToF
Shanghai spatial-computing maker · X-01 · Shanghai, CN · updated 2026-10
Purpose-built for physical-AI data collection with on-device SLAM as a reference trajectory.
FIG. — Egocentric headset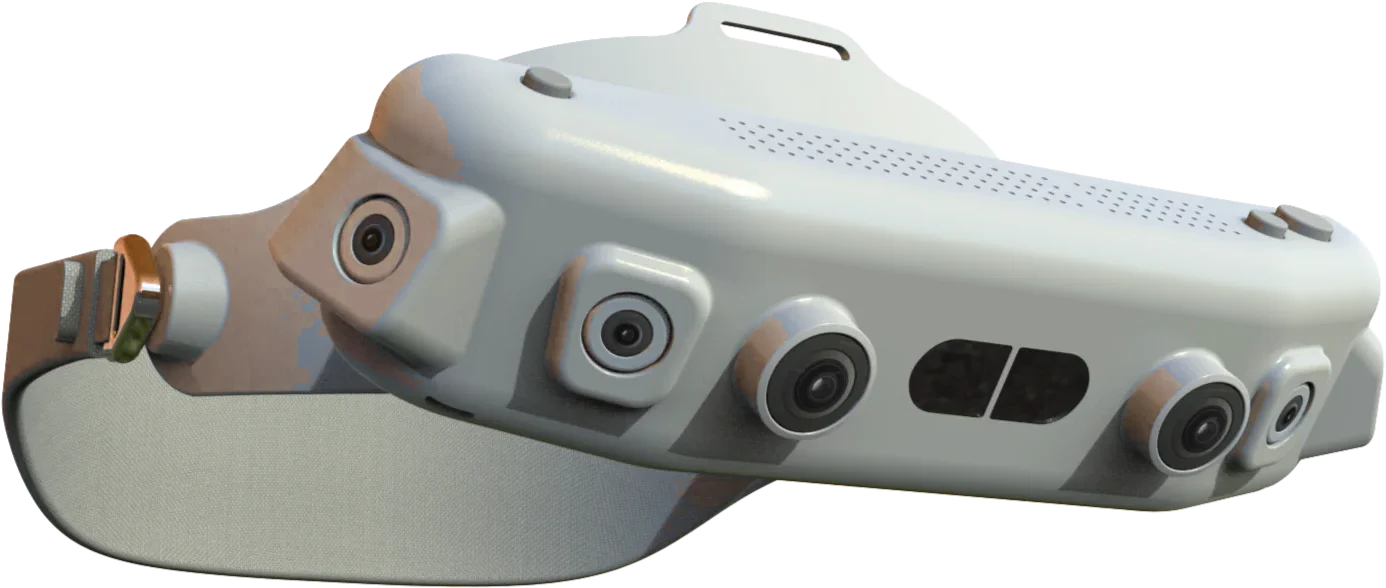
| Tracking cameras | 4 × 640×480 mono global shutter fisheye, 25–50 fps, DFOV ≥ 160°, RAW8, IR pass-through |
| RGB | 2 × 1920×1080 @ 60 fps global shutter, DFOV 179° |
| Depth | ToF 320×240 (optional) |
| IMU | 500 Hz, ±8 g, 2000 dps |
| Compute / I/O | 4×A72 + 4×A53, Debian 12; USB 3.0 device mode or stand-alone |
| SLAM | On-device, RPE < 0.5% (claim) |
| Price band | On request |
| Practices | Robot-learning data hardware |
Watch for
- 640×480 tracking resolution
- H.265 RGB by default
Specifications from supplier documentation; they change between batches — we confirm the exact variant before ordering.