What exists, what it really does, and where to get it.
Devices, modules and parts we source from our network of 100+ suppliers. Global brands are named; OEM routes from our own sourcing are coded — request details and we will come back with the current quote, samples and our notes.
60 entries
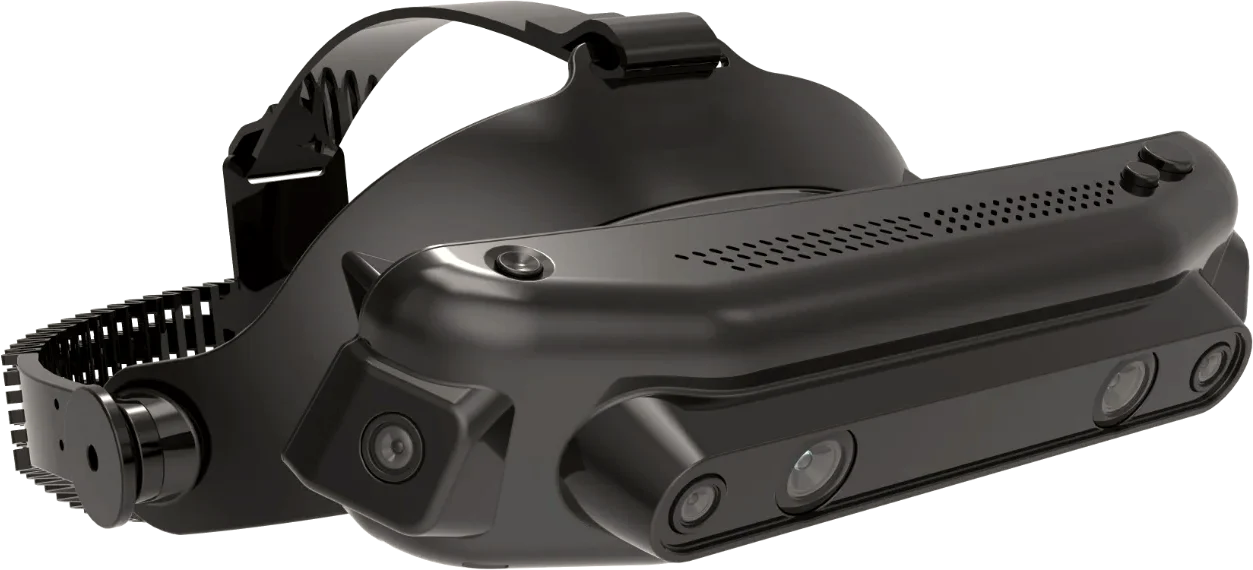
6-camera SLAM data-collection headset
4 × mono global-shutter tracking + 2 × RGB · On-device SLAM SoC; algorithms can be disabled for raw output (vendor confirmed)
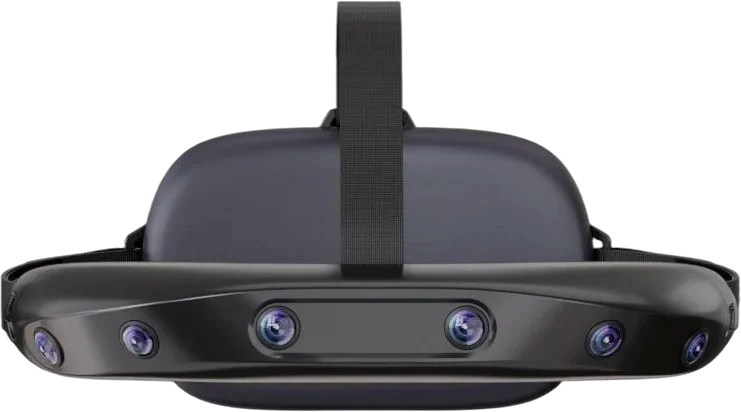
EGO-6 egocentric capture headset (270°, 6 cameras)
6 × colour global shutter, 1600×1300, 30 fps (60 fps option), combined 270° FOV · H160° × V120°, intrinsics stored in EEPROM
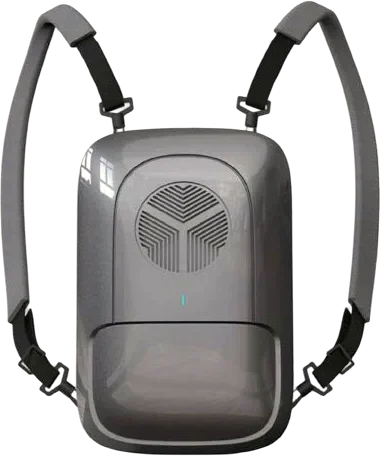
GMSL2 backpack capture system (head band + wrists + EMG)
Front stereo + 2 left + 2 right cameras over GMSL2 · Wrist camera units (GMSL2 + USB-A) and EMG bands (Wi-Fi), left and right
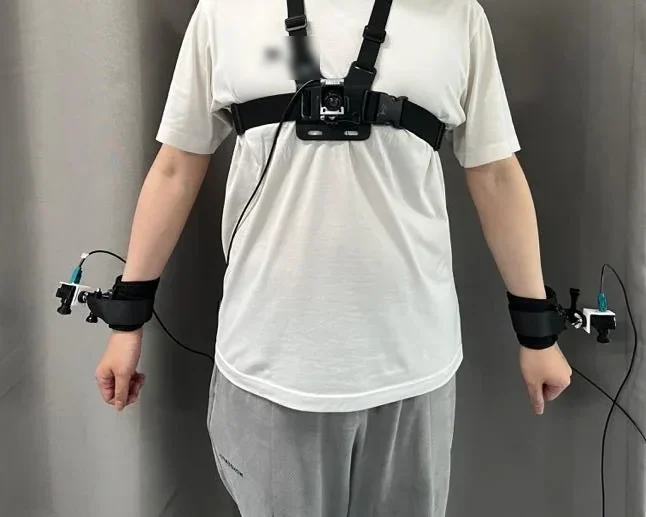
Modular ego + wrist + chest acquisition kit (XR2, PTP)
4-camera SLAM module with full hardware sync + large-baseline stereo RGB · < 250 g head-worn unit (split design)
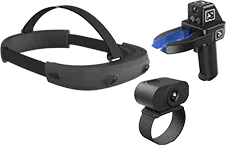
Quad-camera egocentric capture kit (head + wrist + gripper)
4 × 2 MP fisheye · Combined HFOV > 270°
Head-mounted FPV egocentric camera
Egocentric FPV head-mounted camera · Pairs with the same maker's inertial mocap suit
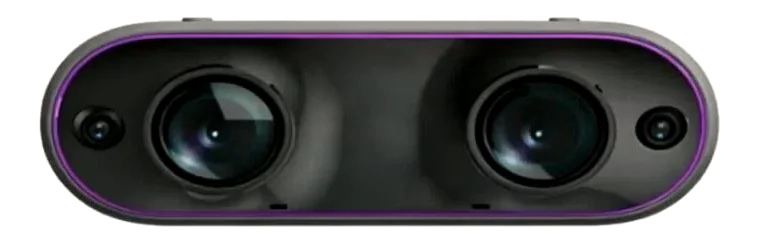
Stereo AR0234 USB3 module, 60 fps MJPEG, trigger pins
2 × AR0234 global shutter, 1/2.6", 3.0 µm, 1920×1200 · 3840/4000×1200 @ 60 fps MJPEG; 30 fps YUYV; USB 3.0 Type-C UVC
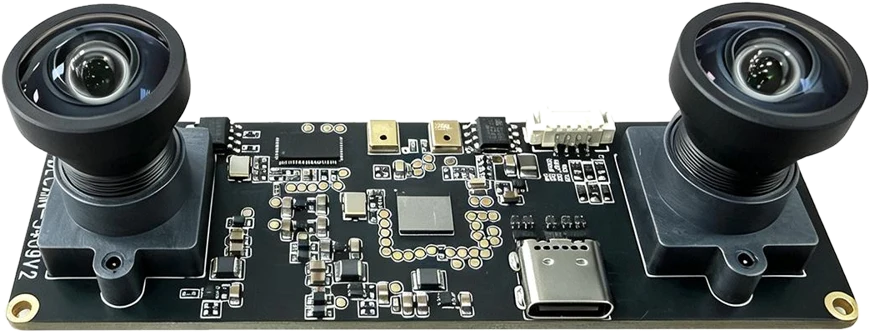
Stereo AR0234 USB3 module, low distortion, 65 mm baseline
2 × AR0234, 1920×1200 · 60 fps MJPEG / 30 fps YUYV, USB 3.0
Stereo global-shutter USB3 module with SD recording
2 × global shutter, 1/2.6", 3.0 µm, 2×1920×1200 @ 30 fps · MJPEG / H.264 / H.265; USB 3.0 UVC, bus-powered
Stereo AR0234 USB3 module, 181° H FOV
2 × AR0234 · 4000×1200 @ 60 fps MJPEG, 30 fps YUY2
Stereo SC235HGS USB2 module, hardware sync
2 × SC235HGS global shutter, 1/2.6", 3.0 µm · 1080p MJPEG 30 fps; YUY2 1080p 15 fps; USB 2.0
OV9281 1 MP mono USB2 module
OV9281, 1280×800, global shutter, mono · USB 2.0 UVC, fixed focus
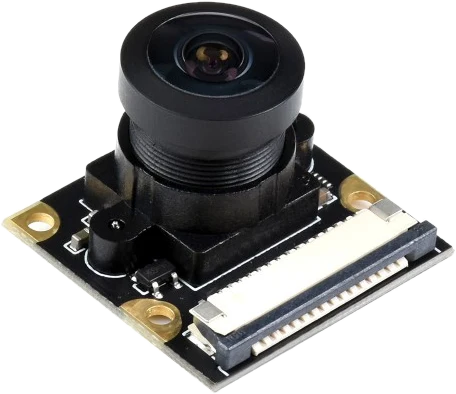
OV9281 160° mono camera, CSI
OV9281 mono global shutter · ~160° FOV
Industrial MIPI OV9281 camera module
OV9281, 1280×800, 120 fps · Documented industrial trigger and driver options
AR0234 MIPI camera with ISP, 120° lens
AR0234 colour global shutter · YUV via ISP, MIPI CSI-2 — 30 fps listed
AR0234 MIPI / GMSL camera module with on-module ISP
AR0234 global shutter with on-module ISP · MIPI CSI-2; GMSL and Pi kit variants
AR0234 colour USB 3 camera
AR0234 colour global shutter · USB 3 UVC
AR0234 USB3 colour module with external trigger
AR0234 colour · USB 3.0
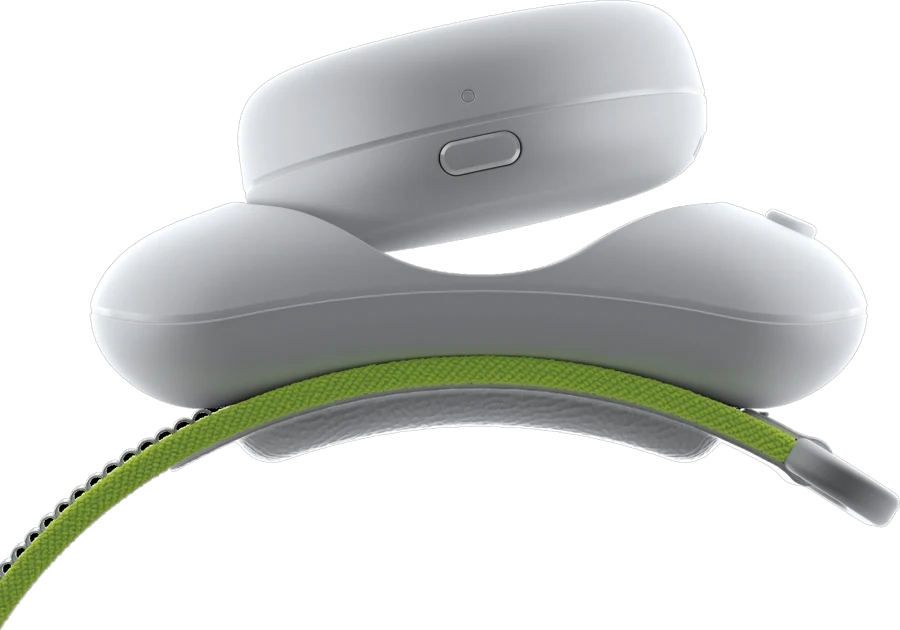
Headset-tracked IR LED body tracker (consumer)
~27 g · IR LEDs + IMU, tracked by the headset cameras
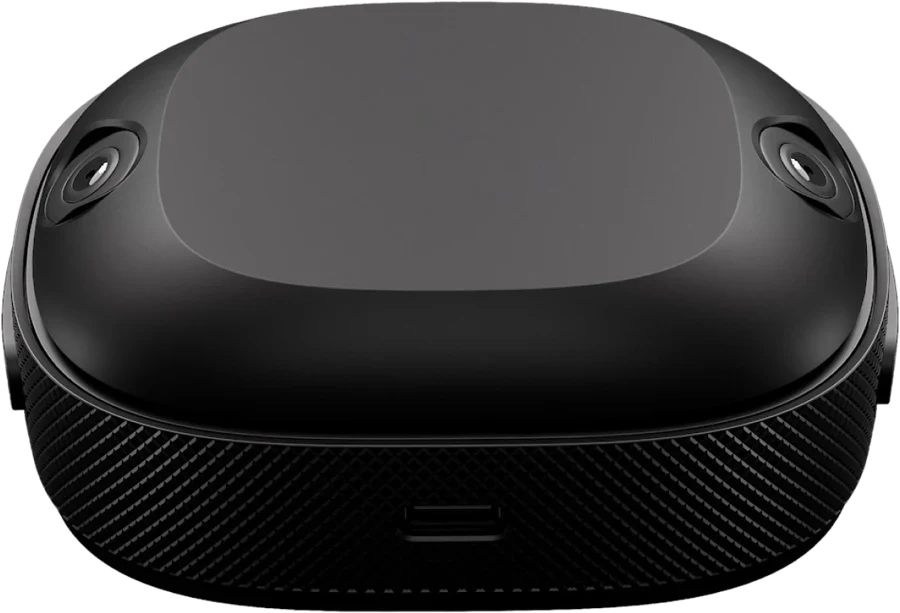
Inside-out self-tracking puck (consumer)
94 g · Self-tracking, two cameras, inside-out
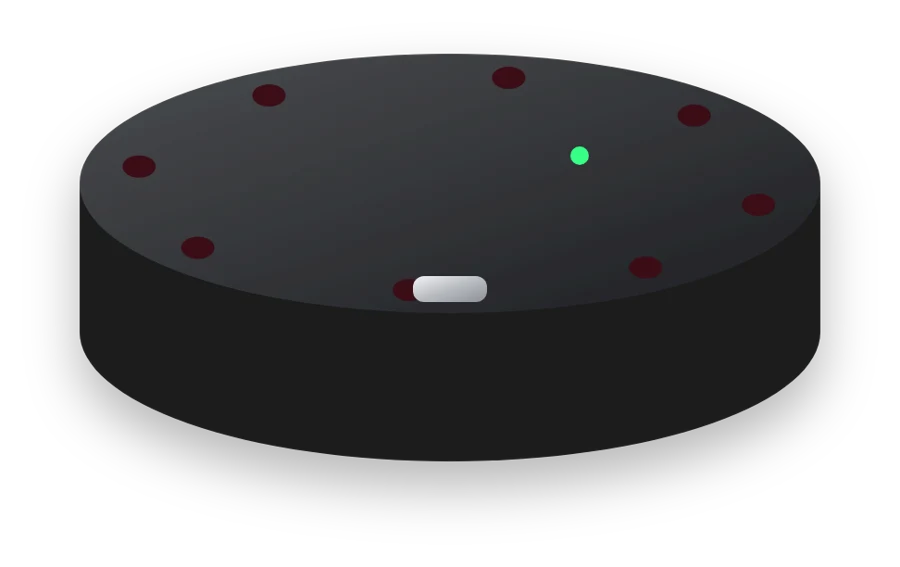
Reference design: 850 nm LED + UWB tracker puck
8–12 × SFH 4253-class 850 nm IR LEDs, pulsed to headset exposure · ICM-42688-P, 1 kHz, SPI, external clock input
27-node inertial mocap suit
27 inertial sensors · 500 Hz internal refresh
Inertial mocap suit (OEM available)
Inertial mocap suit · Established maker; OEM/ODM listed
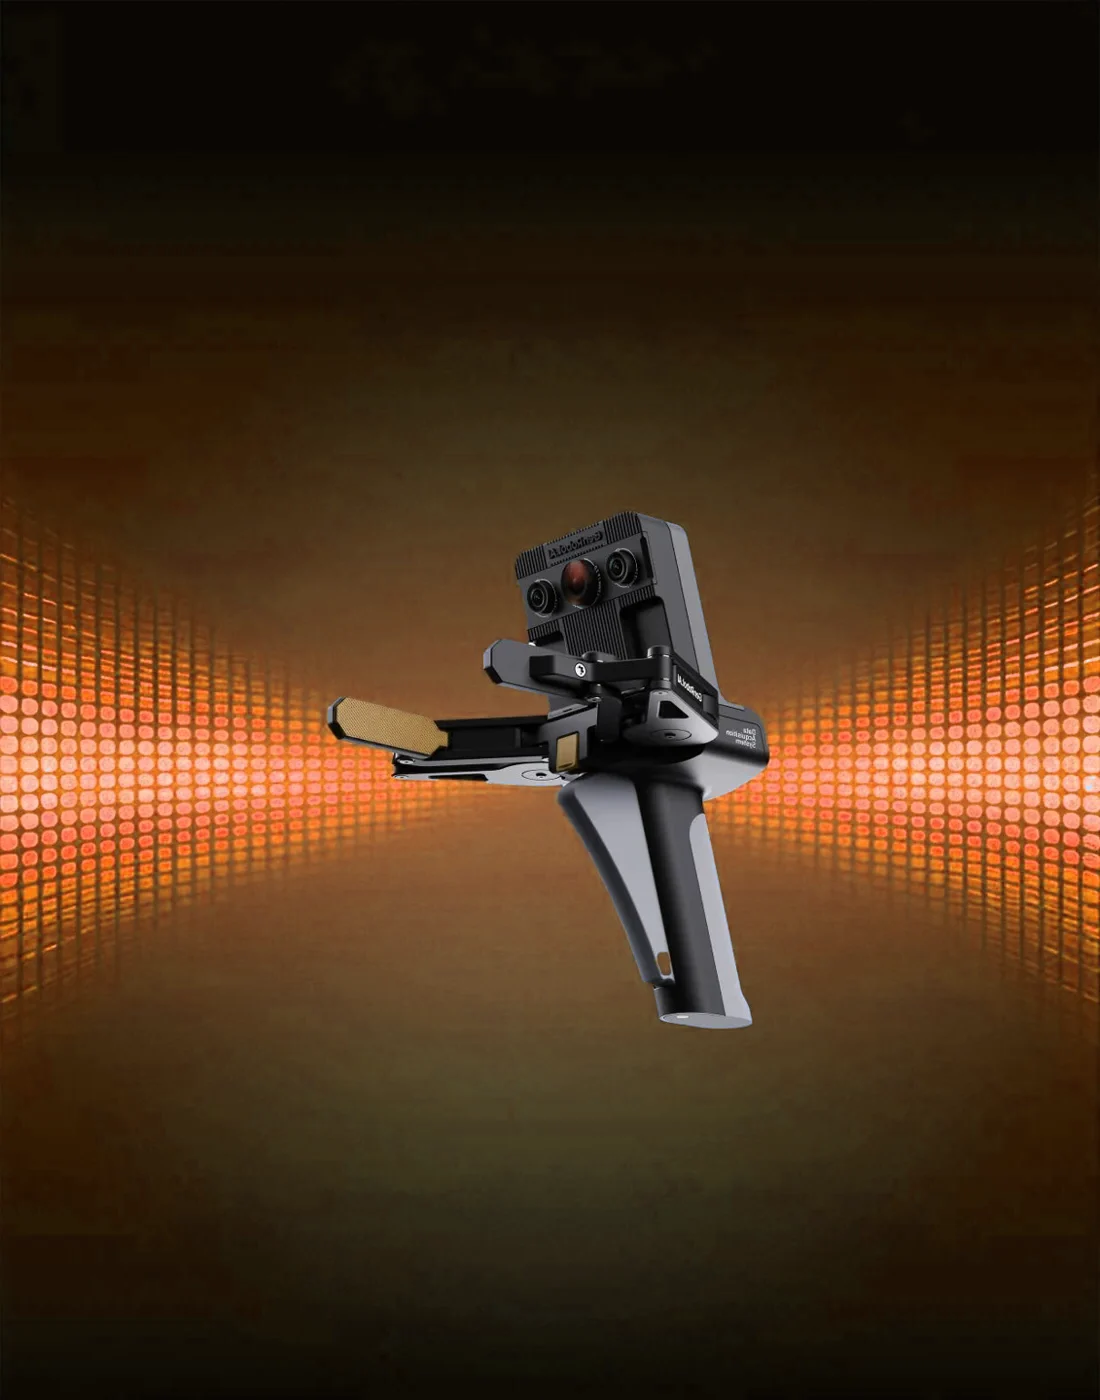
Handheld UMI gripper: 180° binocular + full tactile skin
Automotive-grade global RGB, 180° fisheye binocular · 1 mm flexible full-coverage skin, 7 g – 2.5 kg range
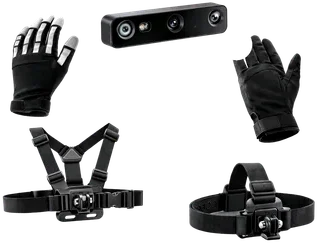
Tactile glove + head/chest vision kit
132 per glove (12 per finger + 72 palm), 5 bend sensors · 0.01 N fingertip; 325 N max
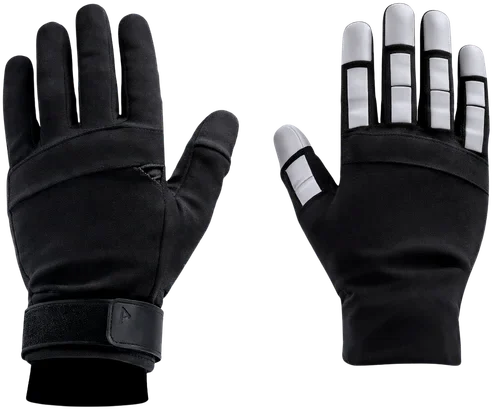
Fingertip pressure-sensing glove, 300 Hz – 1 kHz
12.4 × 15.4 mm per fingertip, 19.87 points/cm² · Trigger ≤ 50 g; up to 10 kg
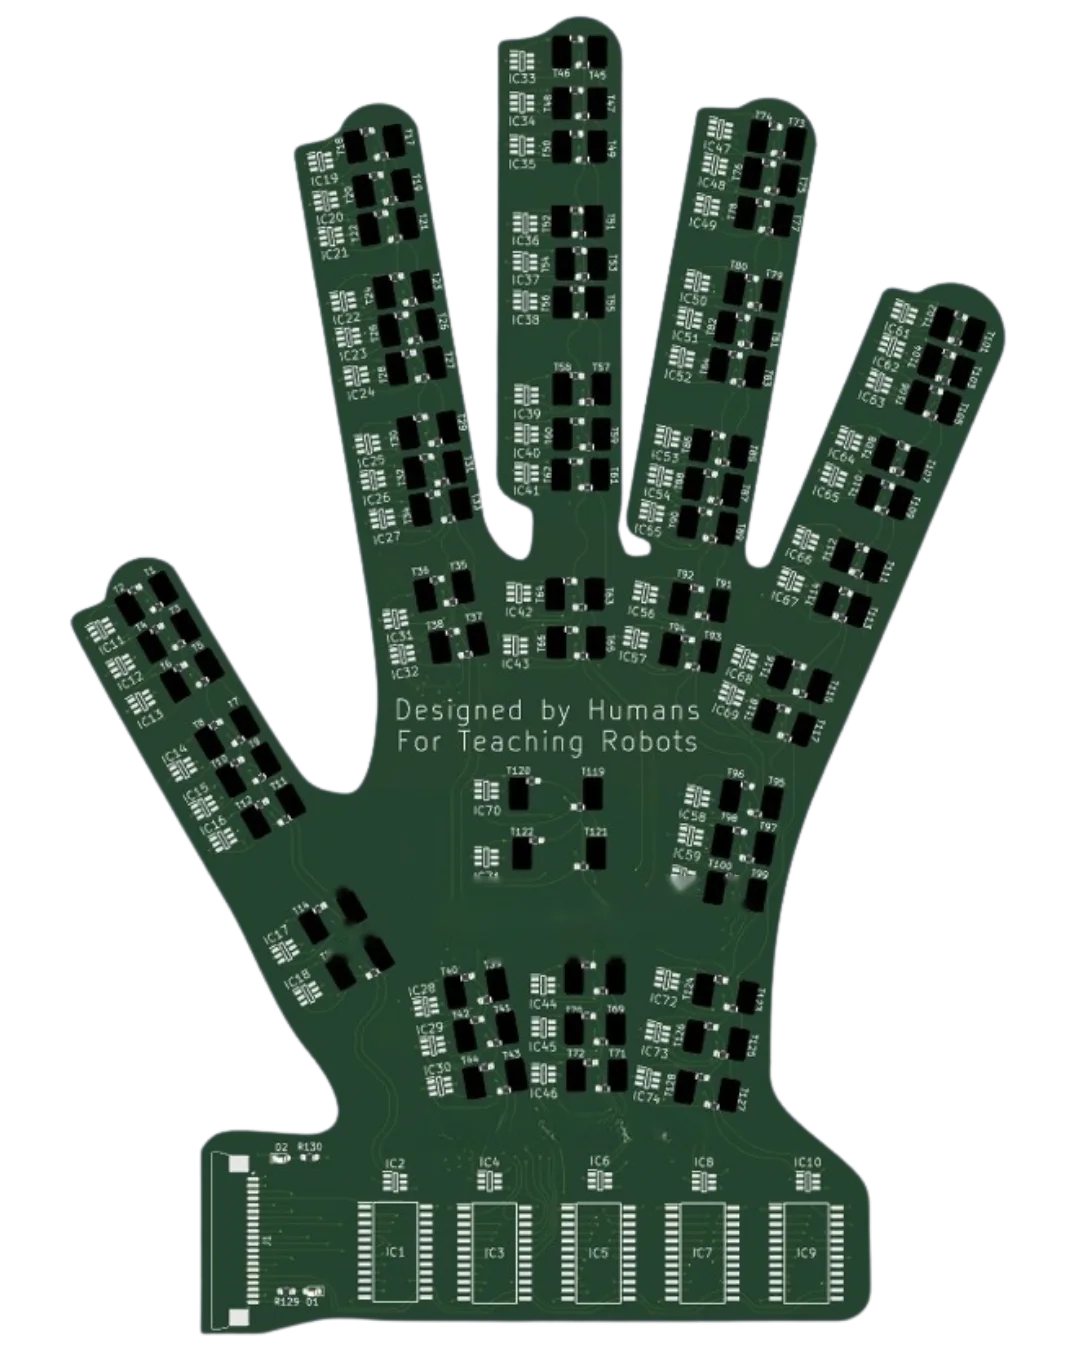
HOLON flex-PCB sensing glove (reference build)
ESP32-S3 · ADS7953 multi-channel SAR
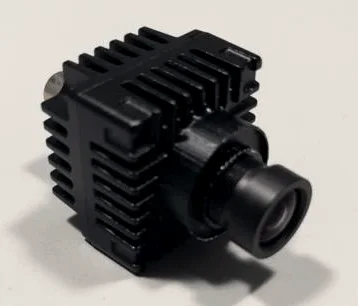
MIPI → GMSL2 4-channel capture platform (Jetson)
MAX96717-class behind each camera · 2 × MAX9296 (2 cameras each) on the carrier
MAX96712 quad GMSL2 deserializer
4 × GMSL2/GMSL1 inputs · MIPI CSI-2
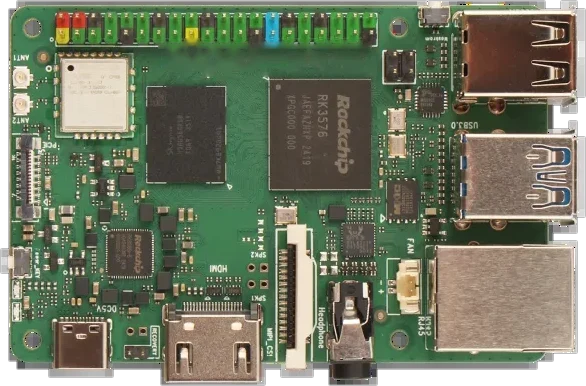
RK3576 single-board computer (PoE option)
RK3576: 4×A72 @2.2 GHz + 4×A53; 6 TOPS NPU · 2× USB 3.0-A, GbE (PoE option), Wi-Fi
RK3576 dual-Ethernet SBC
RK3576, 6 TOPS NPU · 2× USB 3.2 Gen1, 2× GbE, M.2 NVMe, UFS
Allwinner A733 compact SBC
A733: 2×A76 @2.0 GHz + 6×A55; 3 TOPS NPU · USB-C 3.1 host, LPDDR5
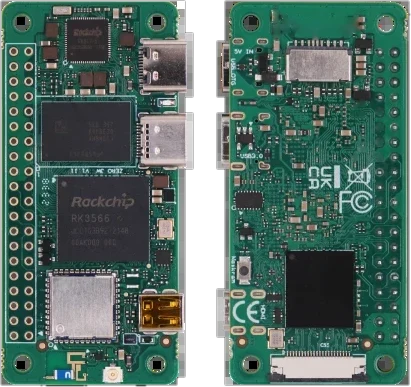
RK3566 compact SBC
RK3566: 4×A55 @1.6 GHz; ~0.8 TOPS · USB 3.0-C host, Wi-Fi 6
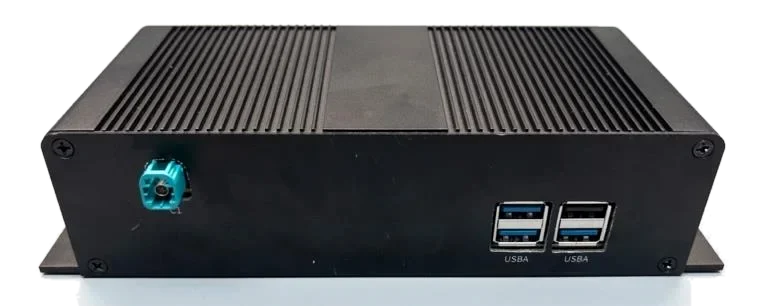
RK3588 fanless edge AI box
RK3588: 4×A76 + 4×A55; 6 TOPS NPU; 8K decode · Multi-stream PoE IP or MIPI
Jetson Orin NX module
Up to 100 TOPS (16 GB, sparse INT8) · Up to 4 MIPI CSI-2 cameras (8 via virtual channels); GMSL via carrier
M12 fisheye lens, F2.0, NIR-corrected, no IR-cut
M12 fisheye, F2.0, NIR-corrected · 186° image circle — not HFOV on OV9281
M12 superfisheye lens, EFL 1.38 mm, IR-cut 650 nm
Fisheye, EFL ~1.38 mm, F2.0 · IR-cut 650 nm on this variant
Visible + 850 nm dual-bandpass filter
Visible + ~850 nm · Custom-cut unmounted or 25.4 mm mounted
ICM-42688-P 6-axis IMU
6-axis; SPI to 24 MHz; 2 KB FIFO · External clock input
ASM330LHHX automotive 6-axis IMU
6-axis, automotive AEC-Q100, −40 to +125 °C · 833 Hz → 1667 Hz (no native 1,000 Hz)
ICM-45686 6-axis IMU
6-axis BalancedGyro; up to 8 KB FIFO; ±4000 dps
QM35825 UWB SoC
Integrated Cortex-M33 · 4 RF ports; channels 5/9; ranging and AoA
BLE + UWB combo module (nRF52833 + DW3120)
BLE 5.2 + UWB (850 kbps / 6.8 Mbps) · Accelerometer on module
850 nm-class IR emitter (SMD)
860 nm (850 nm class) · Pulsed high-peak / low-duty tracker constellations
STM32L432KC Cortex-M4 MCU
Cortex-M4F, 80 MHz; 256 KB flash, 64 KB SRAM · 2 × SPI, DMA, timers for LED scheduling
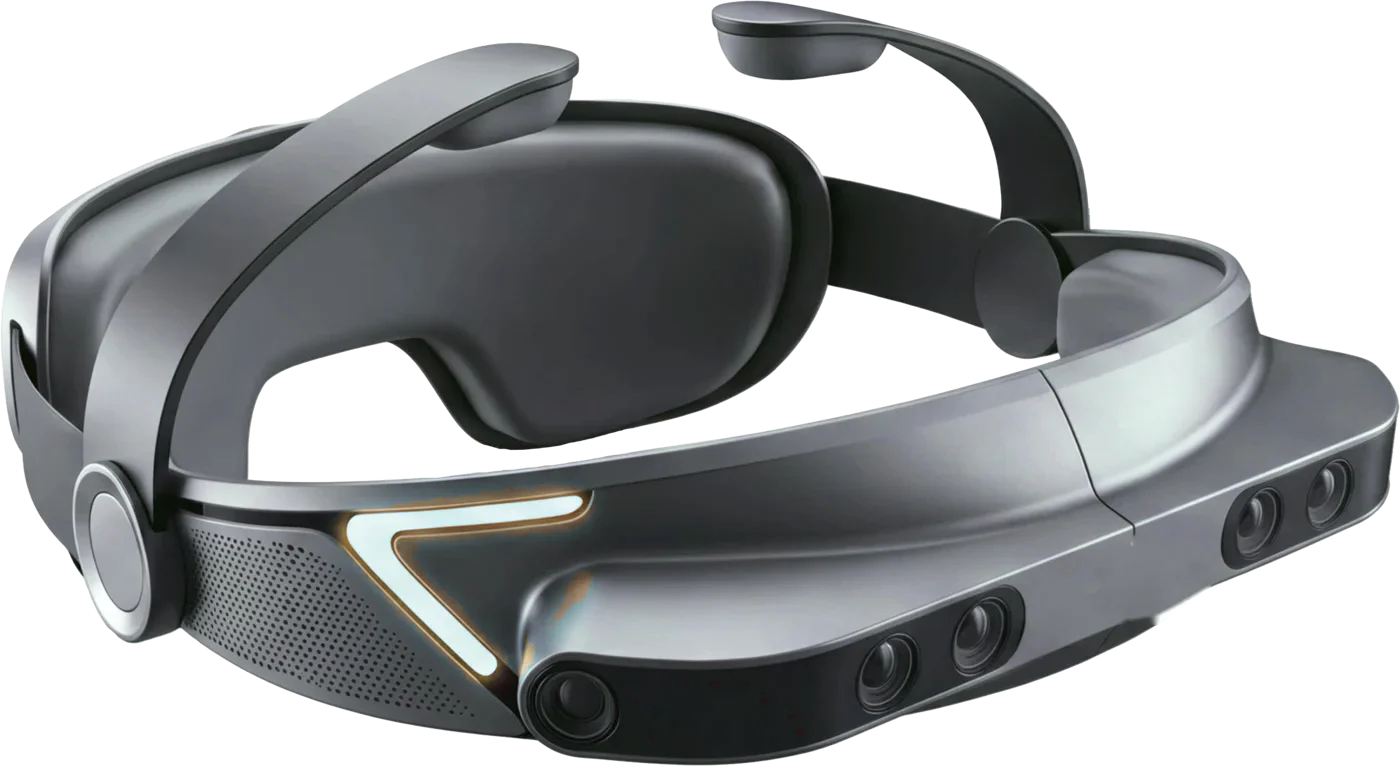
Head-mounted 6-camera data terminal (FPGA sync)
3 binocular pairs: wide RGB ×2, fisheye RGB ×2, wide IR ×2 · FPGA unified trigger; sub-microsecond across RGB / IR / IMU / audio (claim)
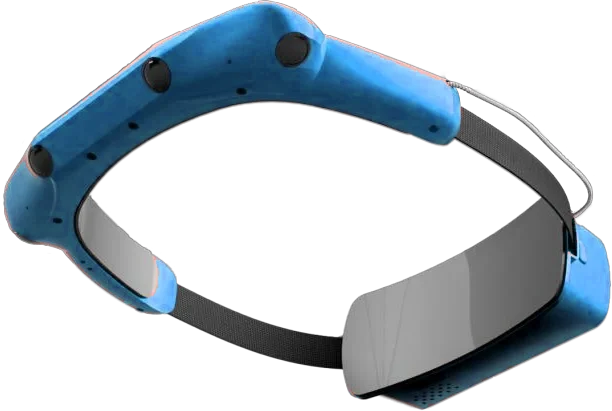
RK3576 four-camera egocentric headset
4 × 2.3 MP global shutter, 1920×1200 @ 30 fps (up to 60) · 206° × 117°
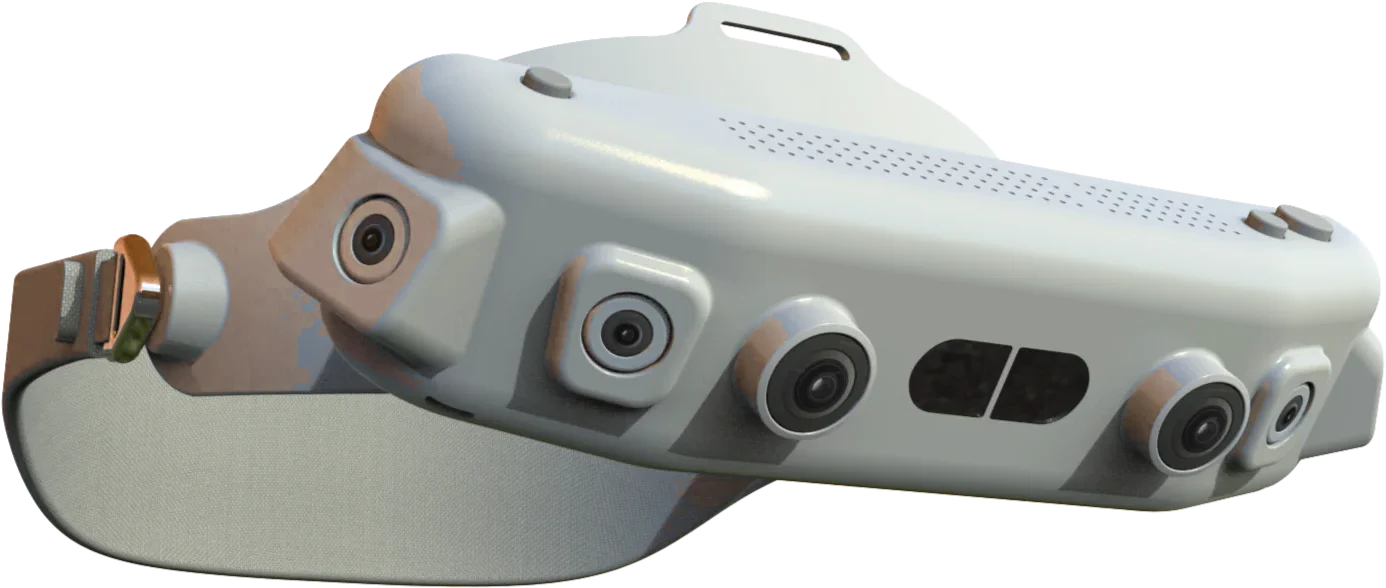
Data-collection HMD: 4 fisheye + 2 RGB + ToF
4 × 640×480 mono global shutter fisheye, 25–50 fps, DFOV ≥ 160°, RAW8, IR pass-through · 2 × 1920×1080 @ 60 fps global shutter, DFOV 179°
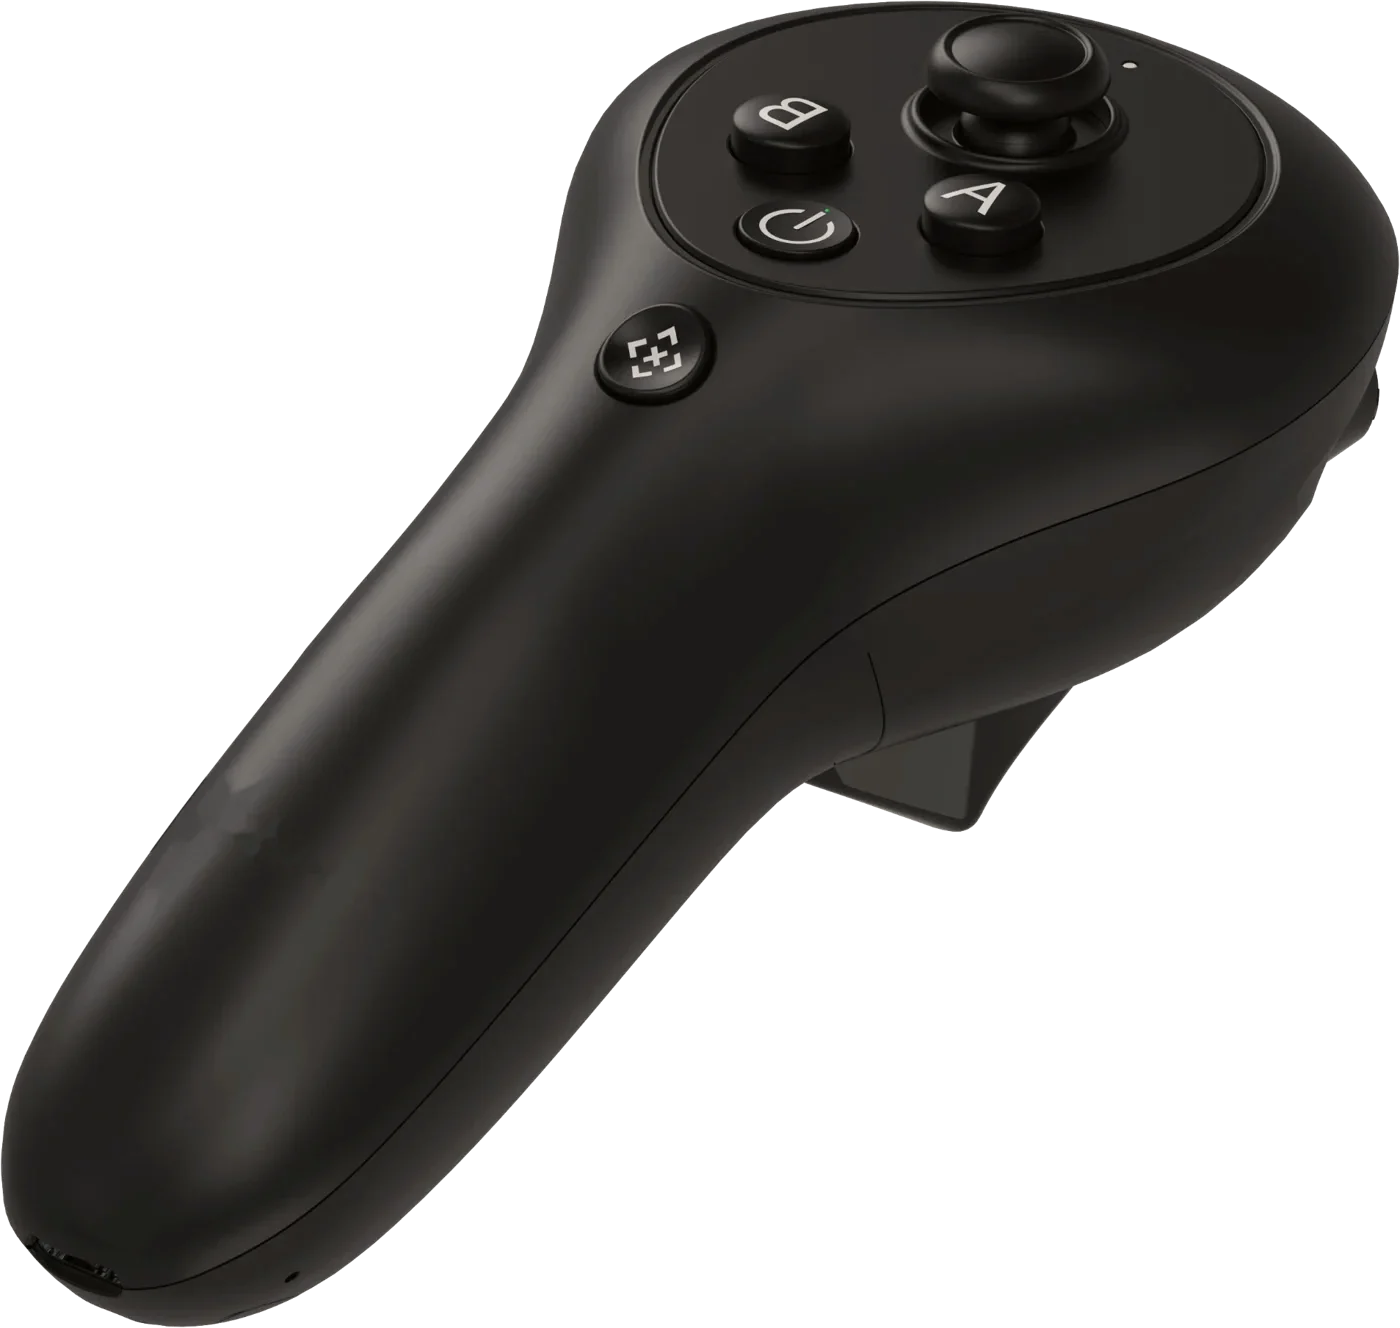
6DoF self-tracking controller
Inside-out visual SLAM, 2 × 640×480 mono global-shutter fisheye, DFOV 160° · 6-axis, 1000 Hz
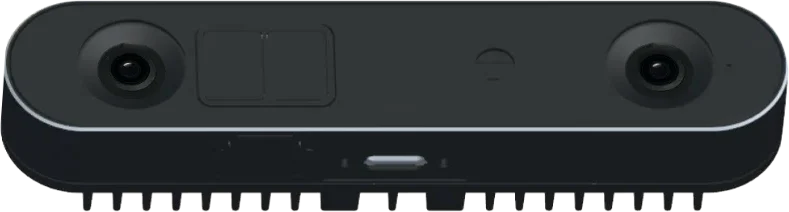
Stereo SLAM + depth sensing module
On-module VSLAM + SGBM depth engine · UMI data acquisition, robot navigation, mowers, vacuums
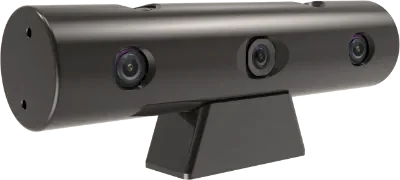
Multi-camera sensing bar
Edge VSLAM + depth, data-acquisition variant · Stand / bracket
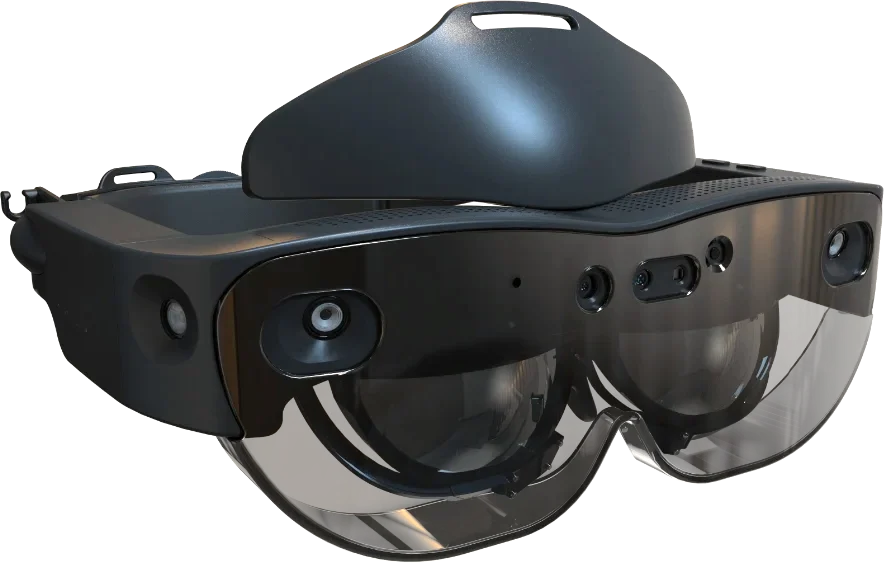
Enterprise MR headset (4 fisheye + RGB + ToF)
4 × mono fisheye 640×480 @ 50 fps; 13 MP AF RGB; ToF 640×480 · 9-axis, 1000 Hz
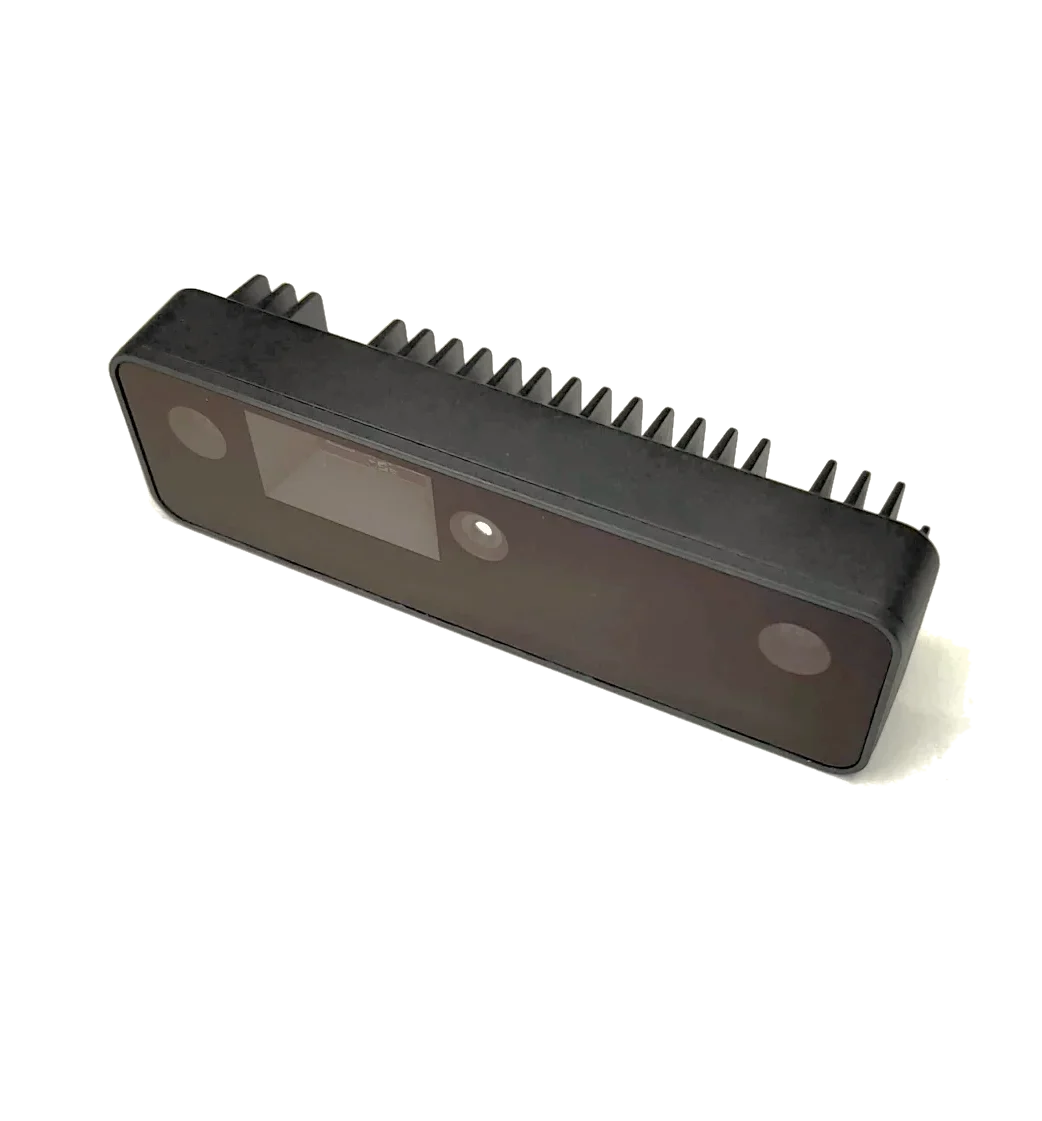
Active-stereo depth + AI camera
2 × OV9282 1 MP global shutter, no IR filter, up to 120 fps · IMX378 12 MP, 4056×3040
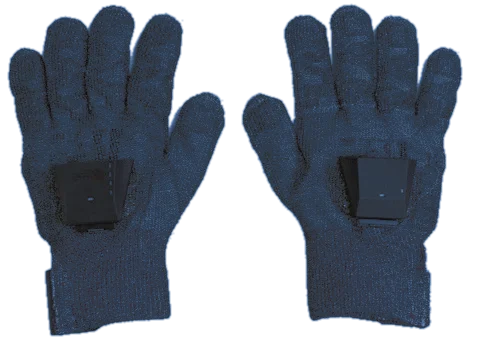
65-element wireless pressure glove
65 tactile elements across palm and fingers · BLE wireless, battery powered
Head + wrist + chest acquisition kit (worn)
Head unit, two wrist stereo cameras, chest camera, hub · Hardware; PTP expansion
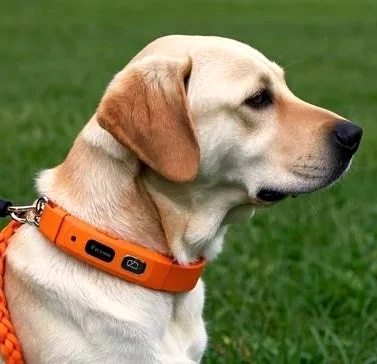
4G pet tracker with BCG heart & respiration
4G LTE Cat.1 · GPS + BeiDou + Wi-Fi + LBS
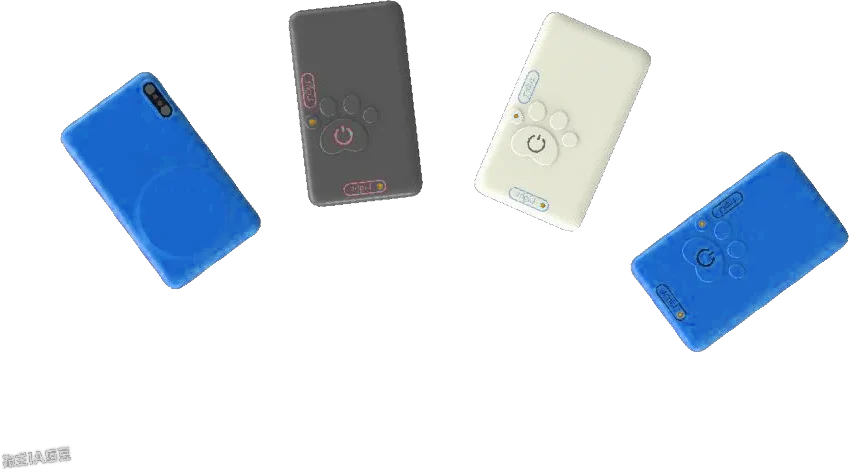
Compact 4G pet GPS tracker
4G LTE Cat.1 · 42 × 42 × 21 mm; 27.5 g; IP67
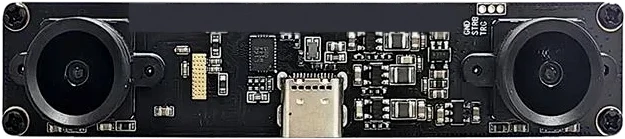
Stereo 1 MP global-shutter USB 3 board, trigger pins
2 × 1/4" global shutter, 1280×800, 3.0 µm · 2560×800 @ 60 fps MJPEG / 30 fps YUV; 1280×800 up to 120 fps
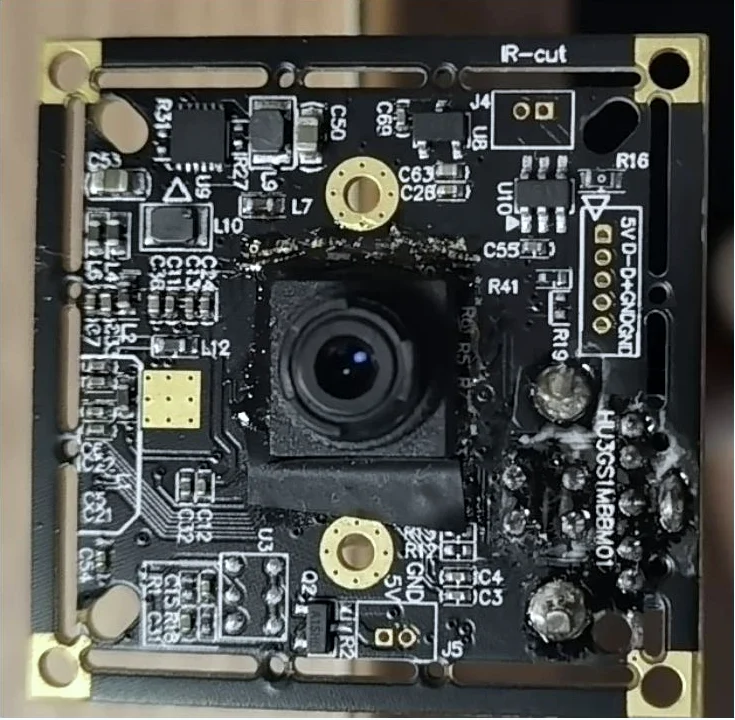
OV9281 mono global-shutter USB camera board
OV9281, 1 MP monochrome global shutter · MJPG / YUY2 over USB
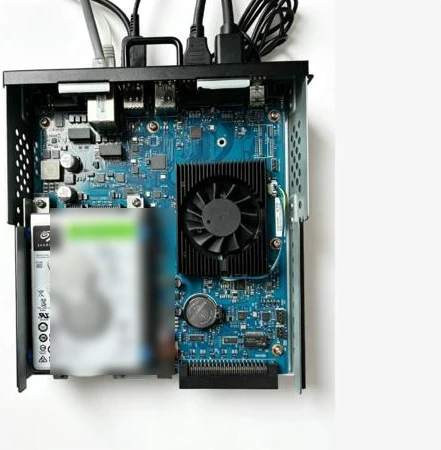
RK3588 compact edge host (3 × GbE, PoE, SATA)
RK3588: 4×A76 + 4×A55, Mali-G610, 6 TOPS NPU · 8 GB RAM, 16 GB eMMC, 2.5" SATA bay
Need the vendor behind a coded entry?
Tell us which entries and your quantity. We will share the identity, current quote and our notes.