What we learn evaluating hardware, written down so you don't repeat it.
Every piece has a document ID, version, named author and reviewer, and a short answer at the top. Numbers come from our own evaluations or public sources we cite; vendor names in confidential work are withheld.
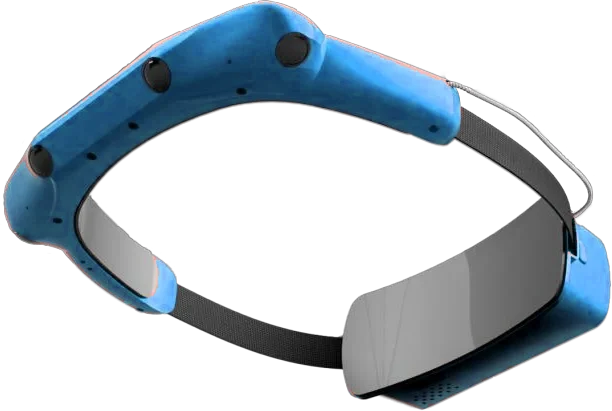
Compute for Capture Devices and Edge Boxes: RK3576, RK3588, Allwinner A733, Raspberry Pi 5 and Jetson Orin
Choosing the processor for a head-worn recorder, a multi-camera capture head or an edge AI box: what each platform is good at, where camera drivers and USB bandwidth bite, and how to benchmark before you commit.
Read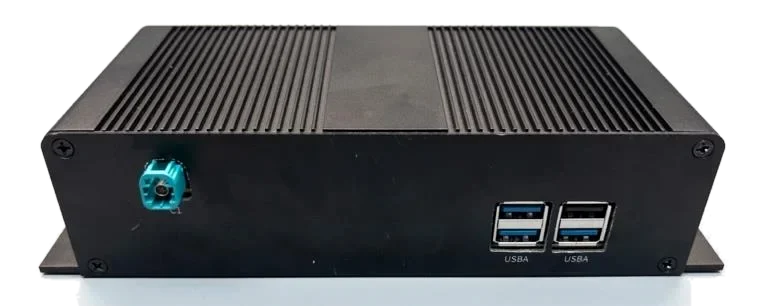
Edge AI Boxes for Retail and Inspection: A Hardware Checklist That Survives the Pilot
What decides whether an edge-vision deployment works after the demo: model-hardware fit, camera links, thermals in sealed boxes, privacy by design, and fleet operations — with a checklist for RK3576, RK3588, Jetson and Hailo-class systems.
Read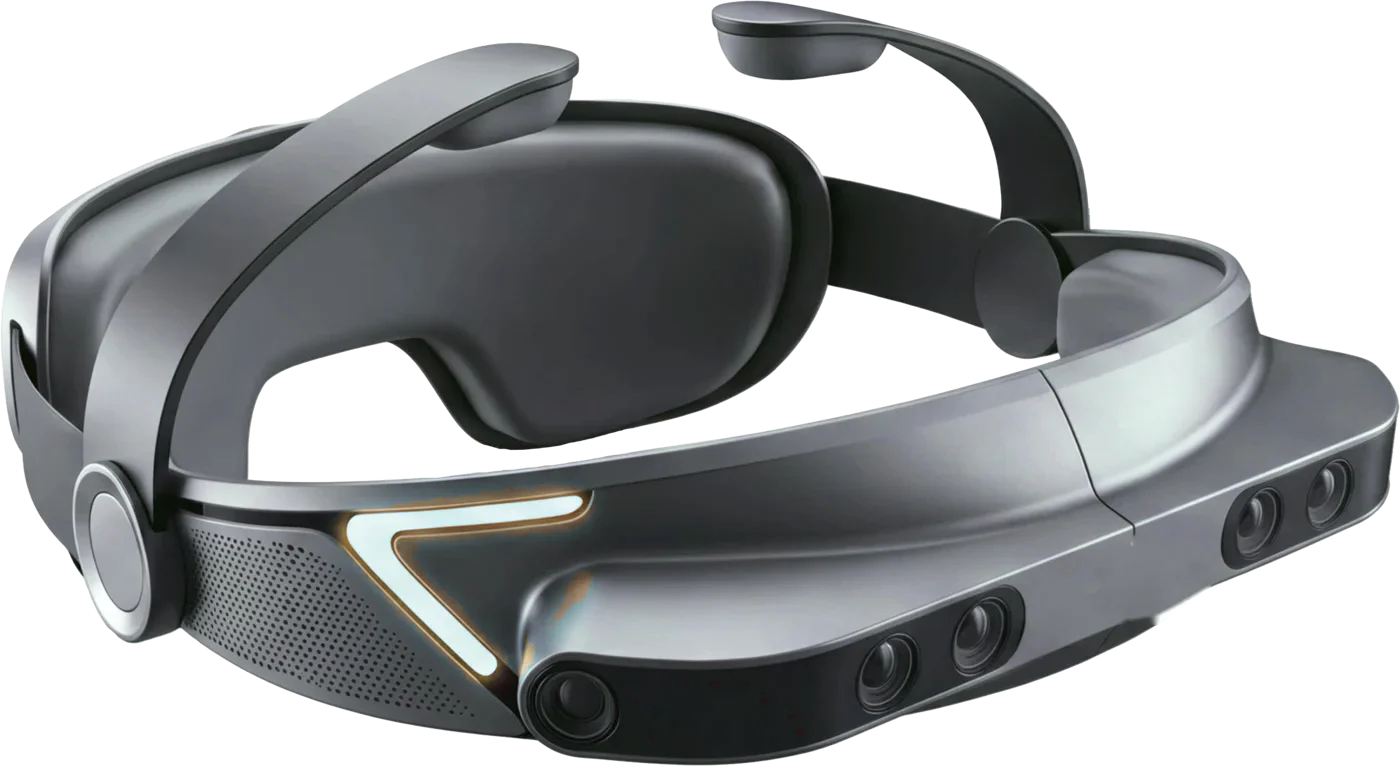
Egocentric Data-Capture Hardware: 2026 Buyer's Benchmark
Five classes of egocentric capture device for robot learning — from phone rigs to six-camera SLAM headsets and custom builds — with specifications that matter, price and NRE bands from real 2026 quotes, failure patterns and a selection framework.
Read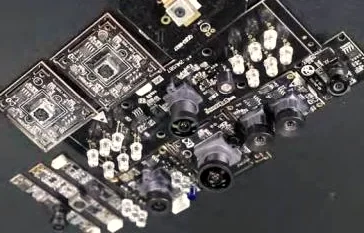
Global-Shutter Sensors for Robot Tracking and Egocentric Capture: OV9281, AR0234, IMX296 and Alternatives
Which global-shutter image sensors suit robot tracking cameras and egocentric RGB, what changes between a sensor datasheet and a shipping module, and the lens and filter mistakes that break near-infrared tracking.
Read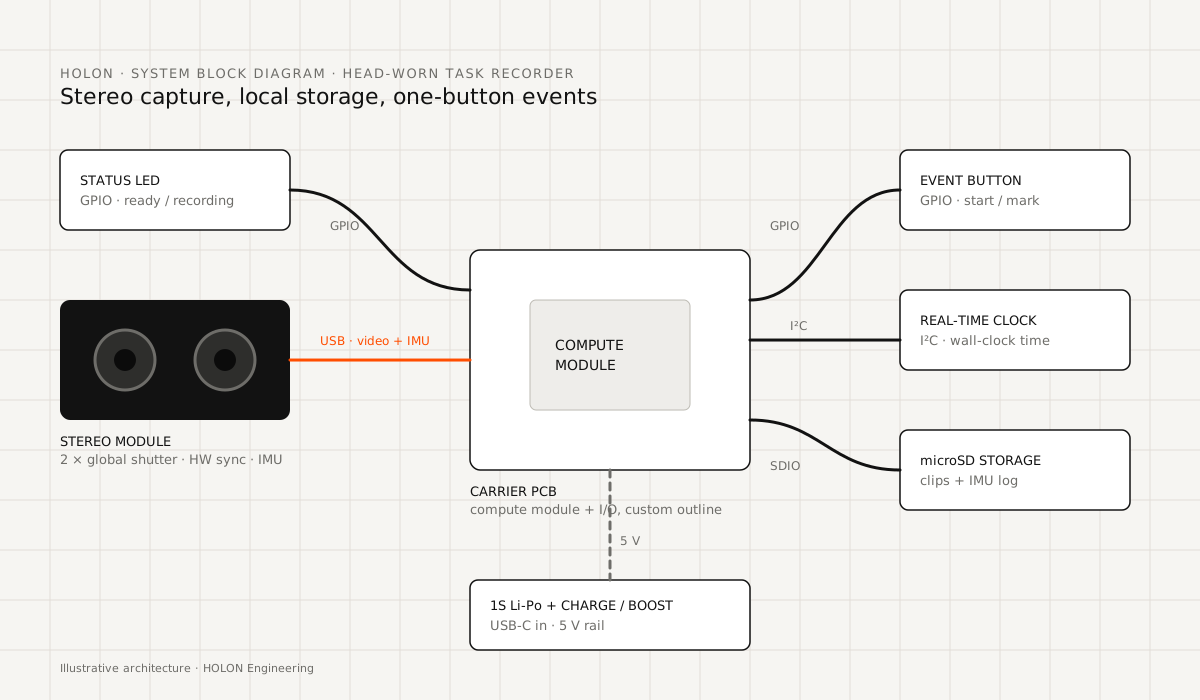
The Hardware RFP Clauses That Decide Who Owns Your Product: Firmware, Data, Calibration and Design Files
What funded hardware startups should write into a Shenzhen vendor RFP before the first sample: data routing, firmware source and escrow, calibration, BOM transparency, design-file transfer, NRE separation and acceptance testing.
Read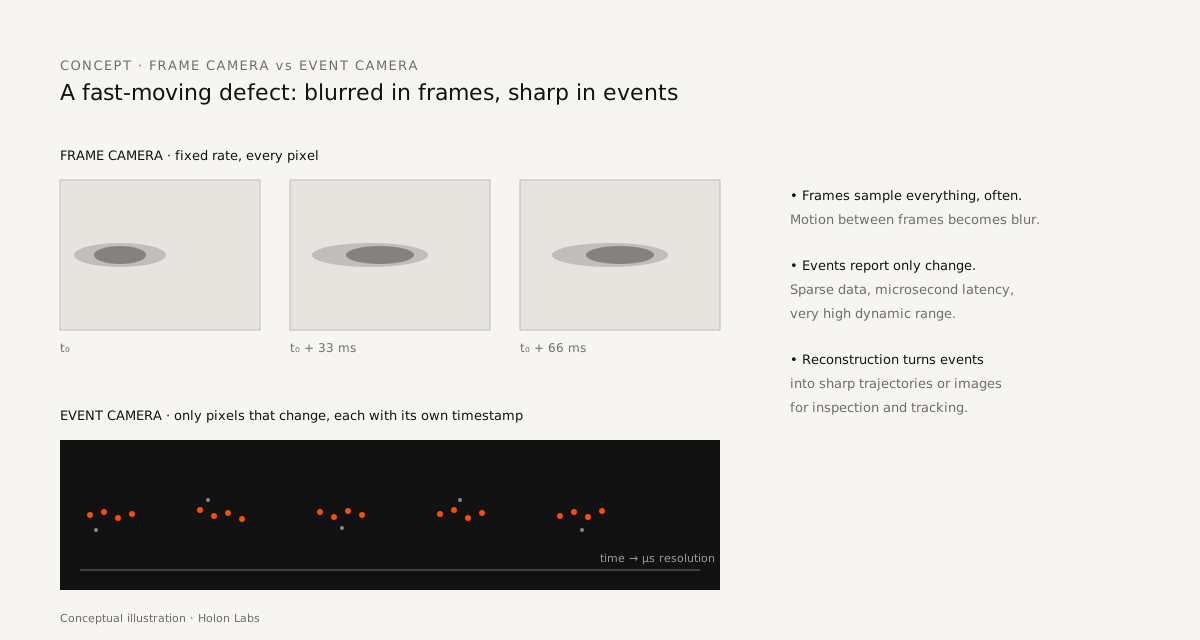
Holon Labs: Event Cameras for Ultrafast Defect Inspection
How neuromorphic (event-based) imaging catches dynamic defects that frame cameras blur, where it fits in industrial inspection and robotics, and how we pilot it.
Read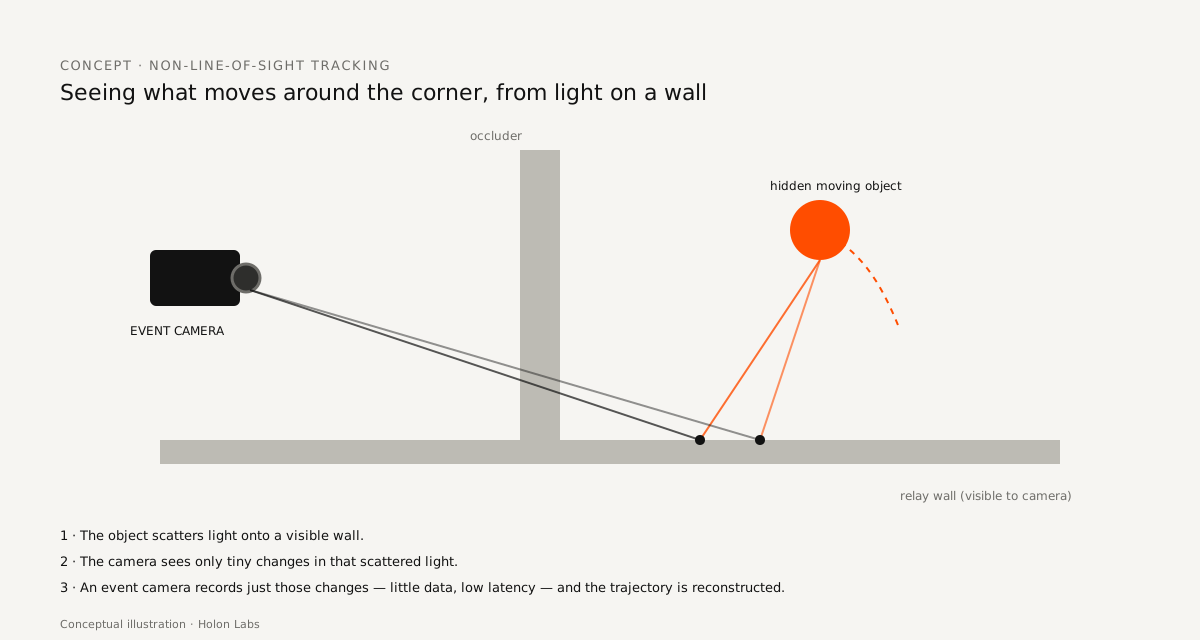
Holon Labs: Neuromorphic Imaging for Tracking Around Corners
Non-line-of-sight tracking with event cameras: what it is, why event data makes it efficient, and what it could mean for robots and safety systems in cluttered spaces.
Read
MIPI, GMSL2, USB3 or 10GbE? Choosing the Camera Link for Multi-Camera Robots
How to move four to eight camera streams from a robot head, wrist or headset to a computer: bandwidth arithmetic, cable reach, synchronisation and driver effort for MIPI CSI-2, GMSL2/3, FPD-Link, USB3 and Ethernet.
Read
Can a Pet Collar Measure Heart and Breathing Rate? An Engineering Evidence Plan
What a collar-mounted motion or pressure sensor can and cannot measure in dogs and cats, why ballistocardiography is hard at the neck, and the architecture and validation plan that keeps product claims honest.
Read
How to Read a Shenzhen Camera-Module Quote (and the Eight Questions That Expose a Bad One)
Camera-module datasheets and quotes from Shenzhen and Dongguan routinely contradict themselves. What to check — sensor, delivered mode, trigger, IMU, distortion, calibration, SDK and price basis — before ordering samples.
Read
Field Notes: Running Egocentric Data Collection Across Southeast Asia
What it takes to collect 10,000+ hours a month of consented, high-quality first-person data across five Southeast Asian countries: sites, consent, participants, devices, QA and upload.
ReadThe Shenzhen Factory-Visit Playbook for Hardware Founders
How to plan a three-to-five-day supplier trip to Shenzhen and Dongguan that ends with decisions, not business cards: pre-qualification, agenda, what to see on the floor, questions to ask, and the follow-up that keeps momentum.
Read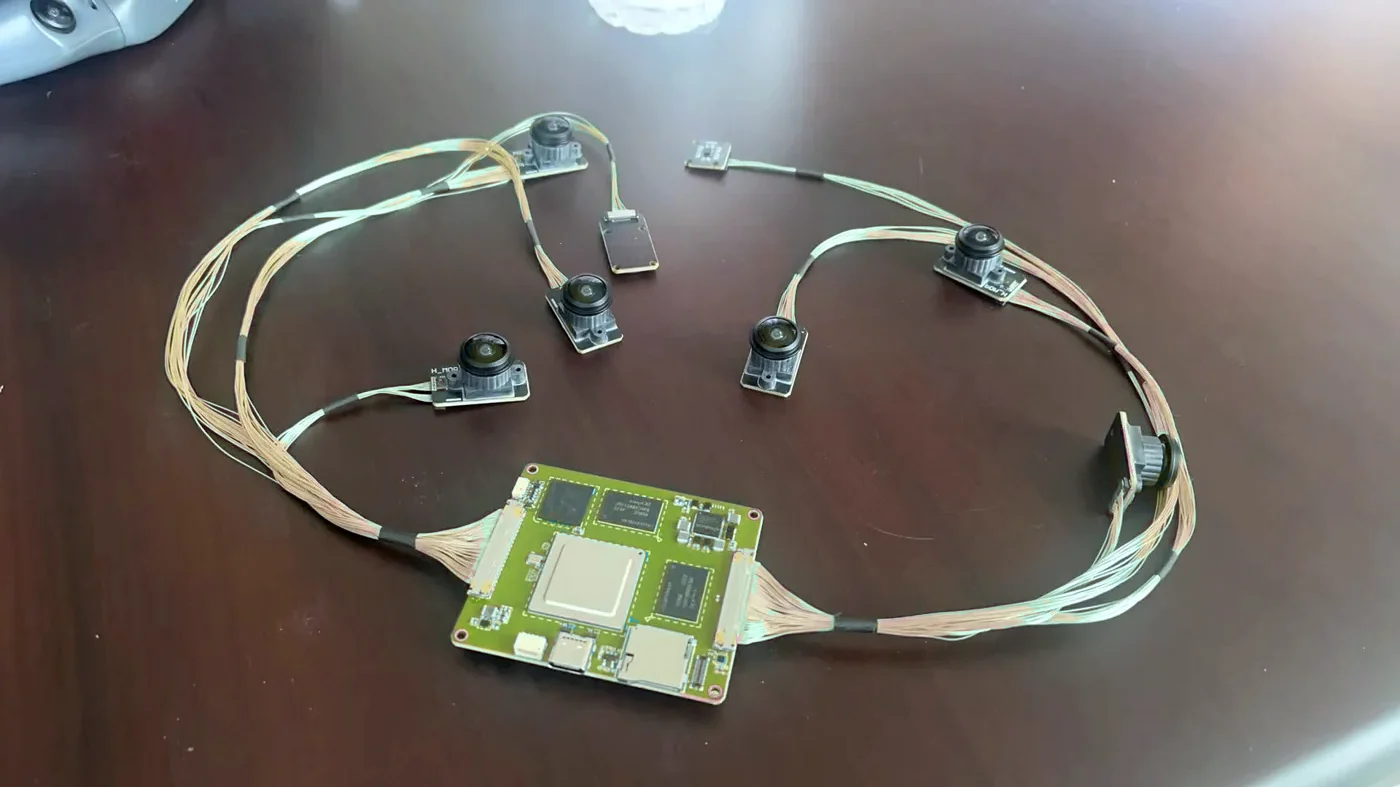
Timing Is the Spec: Synchronisation Requirements for Robot-Learning Capture Hardware
What 'synchronised' actually means for egocentric rigs, trackers and multi-camera systems, the targets frontier robot-learning teams specify, and the acceptance test that proves a device meets them.
Read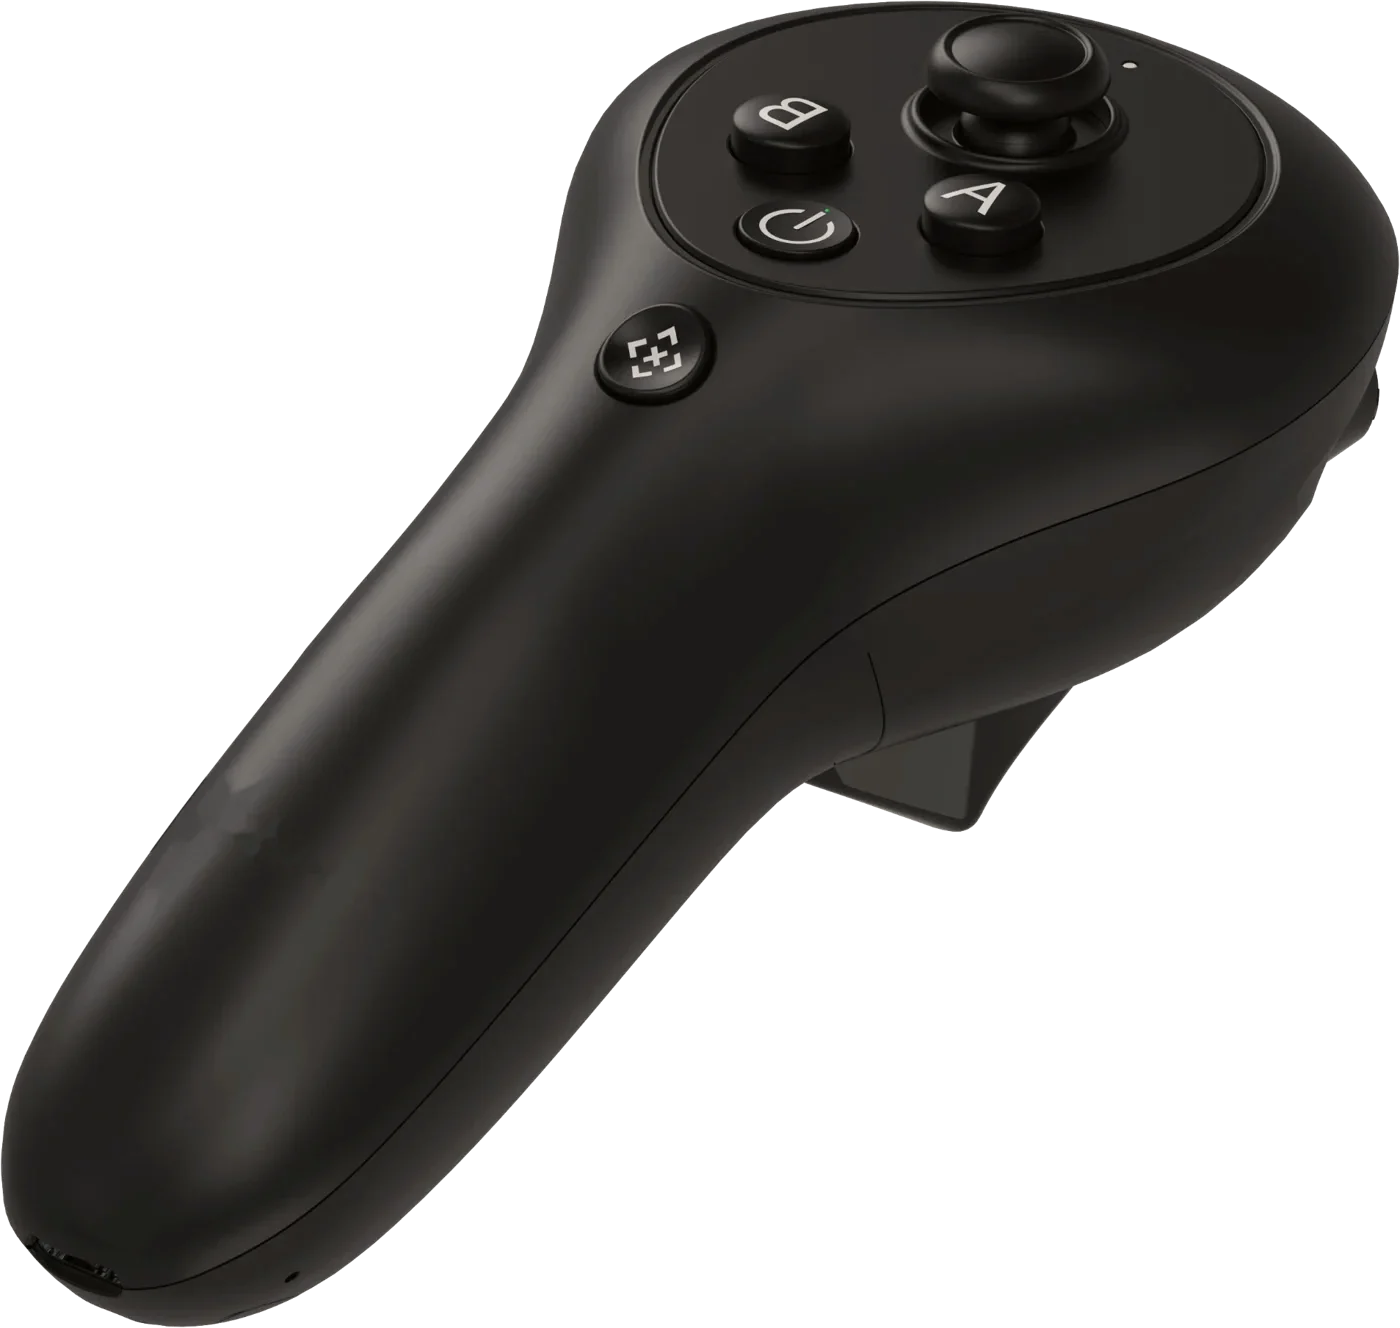
Body and Object Trackers for Robot-Learning Data: LED Pucks, Self-Tracking Pucks, IMU Suits and Custom Designs
How to track hands, feet, torso and objects relative to an egocentric headset: the four tracker architectures, what off-the-shelf options deliver, why tracker count and synchronisation become the bottleneck, and what a purpose-built puck needs.
Read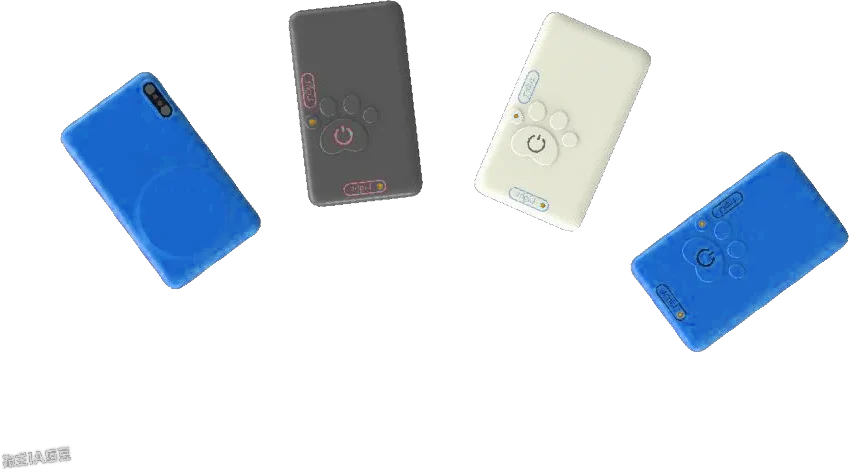
White-Label or Custom? A Dual-Track Strategy for Funded Wearable Startups
How pet collars, smart footwear, rings and earbuds get to market from Shenzhen: when to white-label, when to build, the timelines and volumes that change the answer, and why the data clause matters more than the enclosure.
ReadSubscribe via RSS. Machine-readable index: llms.txt. Definitions: glossary.
Have a hardware question we haven't answered?
Send it. If it is useful to others, we will research it and publish the answer — with your name kept out.